Atelier Konstanz
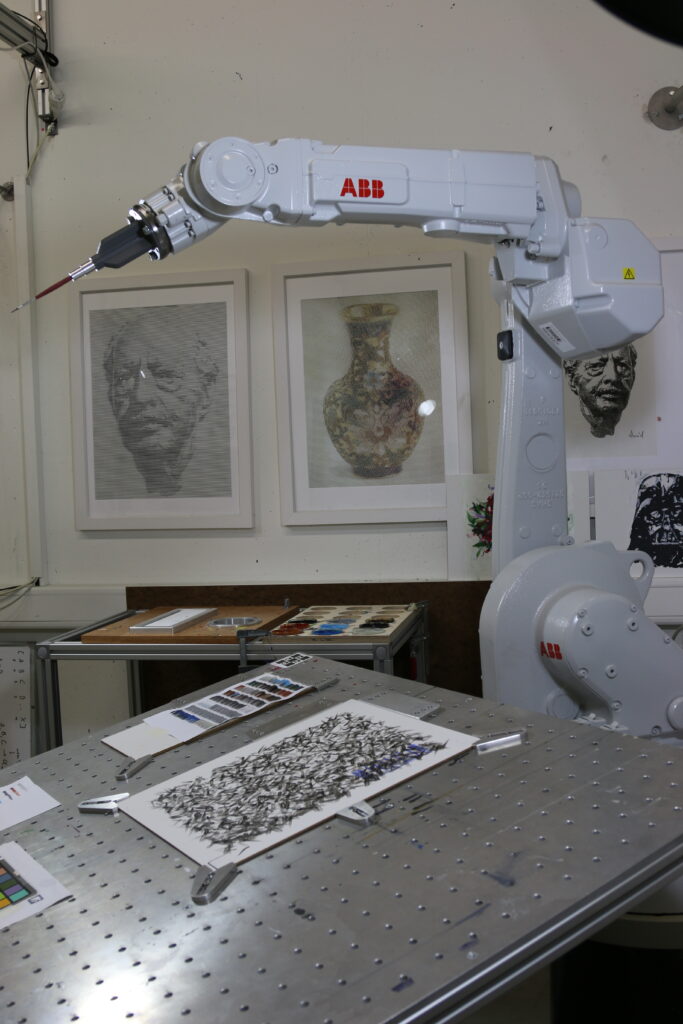
The e-David Painting Robot
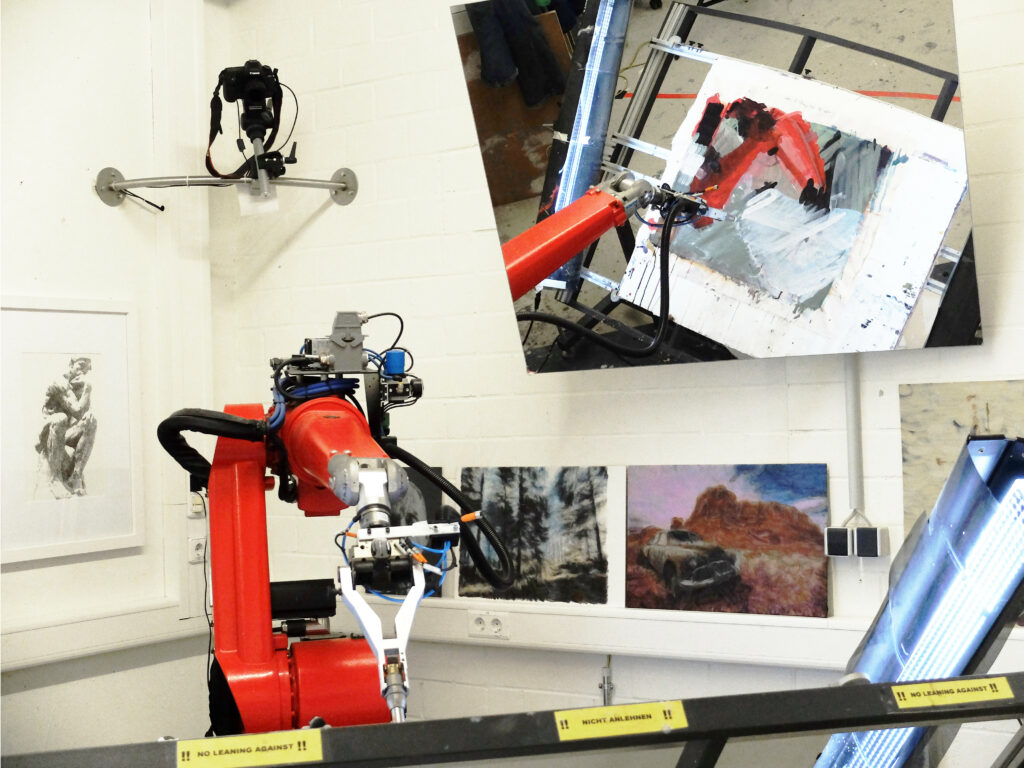
e-David is a long-running art and research project at the Visual Computing group of the University of Konstanz that asks what happens when a machine picks up a paintbrush. Industrial robot arms, normally used for welding or assembly, are equipped with brushes, paint palettes and a camera, so that they can paint real pictures on canvas – and look at their own work while doing so.
Within EACVA, the Atelier Konstanz develops e-David into a creative partner for artists: we research how images can be translated into paintable shapes and human-like brush movements, and we work with artists in residence who paint together with the robot.
More paintings, videos and live streams: edavid.de
e-David at a glance
- Since 2009 – developed by generations of Ph.D. students and artists, supervised by Prof. Oliver Deussen
- 3 machines – a large and a mobile ABB robot arm plus a 2 × 1.2 m plotter
- 1–3 days – for a complete painting of around 1,000–1,500 color regions
- Feedback loop – a camera checks the canvas after each step so the robot can correct itself
How e-David paints
- Choose an image – a photograph, a digital drawing or an AI-generated image serves as the template.
- Abstract it – our software simplifies the image into color regions and layers, keeping important objects detailed and simplifying the rest.
- Plan the strokes – “painting agents” decide how each region is filled – e.g. following its outline or with a stroke pattern – and which color and brush to use.
- Paint and look – the robot paints stroke by stroke, photographs the canvas, compares it to the plan and adds corrections where needed.
Brushes, paint and canvas never behave perfectly: bristles bend, paint drips and the canvas curls, even though the robot itself moves with an accuracy of ±0.01 mm. This mix of machine precision and material unpredictability is what gives e-David’s paintings their character. Artists can also use the robot directly, for example to apply a stroke pattern with a precision no human hand can match, or to paint the same composition in several variations.
Research highlights (EACVA 2023–2026)
During EACVA, the Konstanz and Goldsmiths teams worked together on how a robot can turn an image into a painting that looks – and is made – more like the work of a human painter. Each project below links to the full paper.
Painting by objects: semantic image abstraction
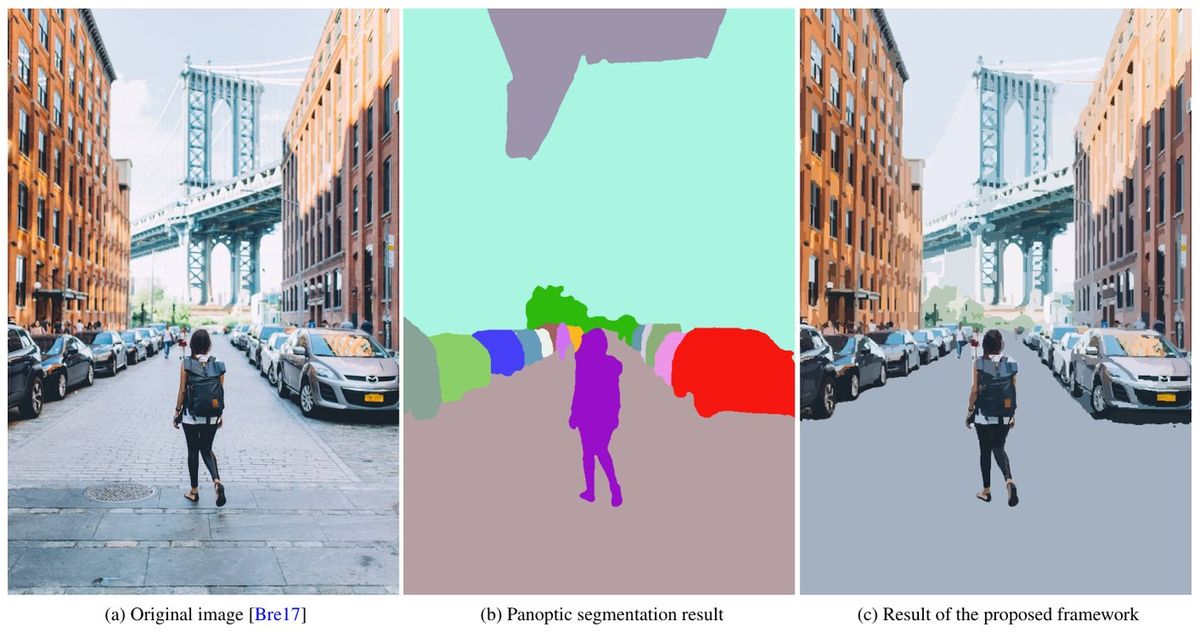
A robot cannot paint millions of pixels – it needs a simplified version of the image made of a manageable number of color regions. We use an AI model that recognizes objects such as people, cars, trees or sky, and let each object get its own level of detail: important things stay detailed while the background is simplified. Users can choose which objects to emphasize. The result is a set of around 1,000–1,500 shapes that e-David can paint in about a day.
Paper: Stroh, Gülzow, Deussen. Semantic Image Abstraction using Panoptic Segmentation for Robotic Painting. VMV 2023. doi.org/10.2312/vmv.20231235
Knowing what matters: saliency-guided abstraction
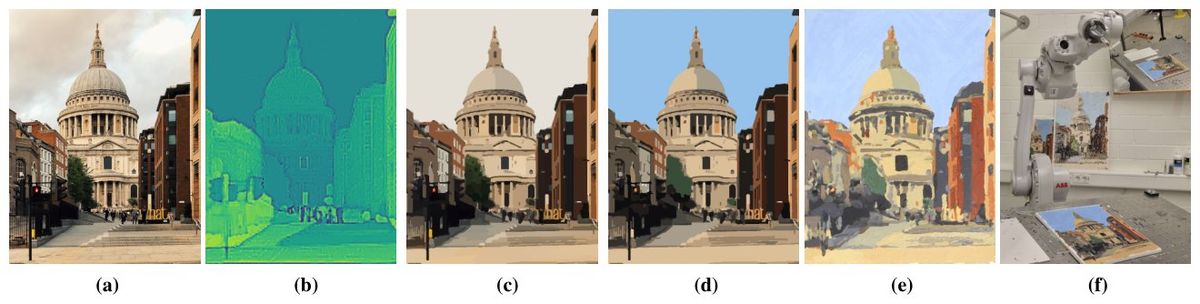
How much detail should each part of a painting have? Instead of setting this by hand, our method estimates which parts of an image attract attention (a “saliency map”) and uses it to decide automatically where regions are merged and where boundaries must be kept. A graph-based grouping step then clusters neighboring regions that belong together. The result is not one abstraction but a hierarchy of layers – from coarse to fine – that the robot paints one after the other, much like a painter who first blocks in large areas and then adds details.
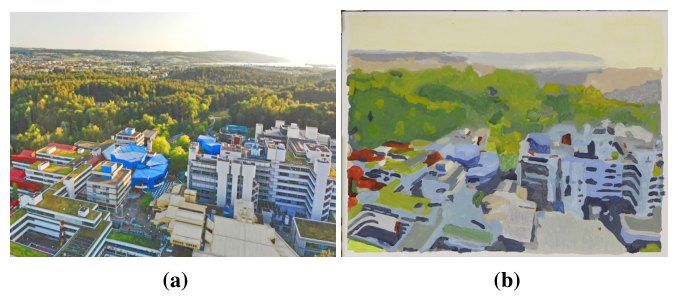
The method is fast compared with optimization-based vectorization, so several abstraction levels can be generated in seconds and then painted with the e-David system on real canvases.
Papers:
Stroh, Paetzold, Berio, Kehlbeck, Fol Leymarie, Deussen, Faraj. Using Saliency for Semantic Image Abstractions in Robotic Painting. Computer Graphics Forum 44(7), 2025. doi.org/10.1111/cgf.70259
Stroh, Paetzold, Berio, Fol Leymarie, Kehlbeck, Deussen. Robotic Painting using Semantic Image Abstraction. Expressive 2025. doi.org/10.2312/exw.20251070
Long, smooth strokes: neural image abstraction with B-splines
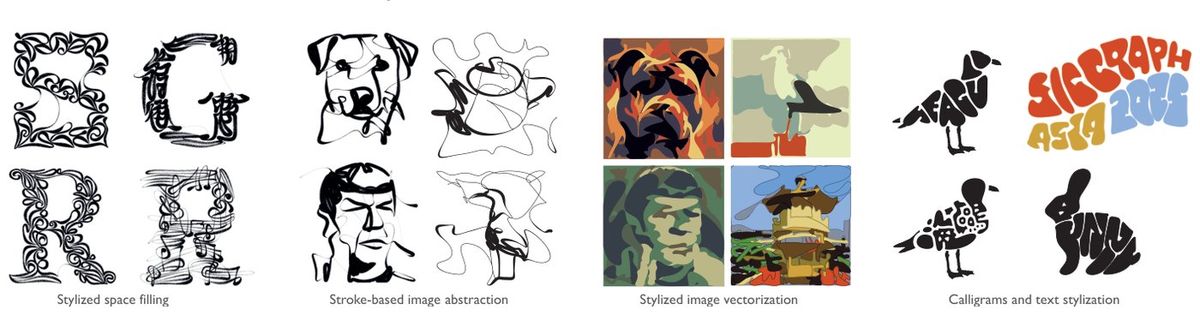
Digital vector graphics usually build long lines by gluing together many short curve pieces – but a brush, a pen or a robot arm works best with long, continuous and smooth movements. Together with Daniel Berio (Goldsmiths), Sylvain Calinon (Idiap) and Ariel Shamir (Reichman University), we integrated smoothing B-splines into a differentiable rendering pipeline. This lets modern image-based AI methods directly optimize long, smooth paths and control the trade-off between fidelity and simplicity, as well as the style of the strokes.
Paper: Berio, Stroh, Calinon, Fol Leymarie, Deussen, Shamir. Neural Image Abstraction using Long Smoothing B-Splines. ACM Transactions on Graphics 44(6), 2025 (SIGGRAPH Asia). doi.org/10.1145/3763345
Drawing like a human hand: rapid lognormal movements
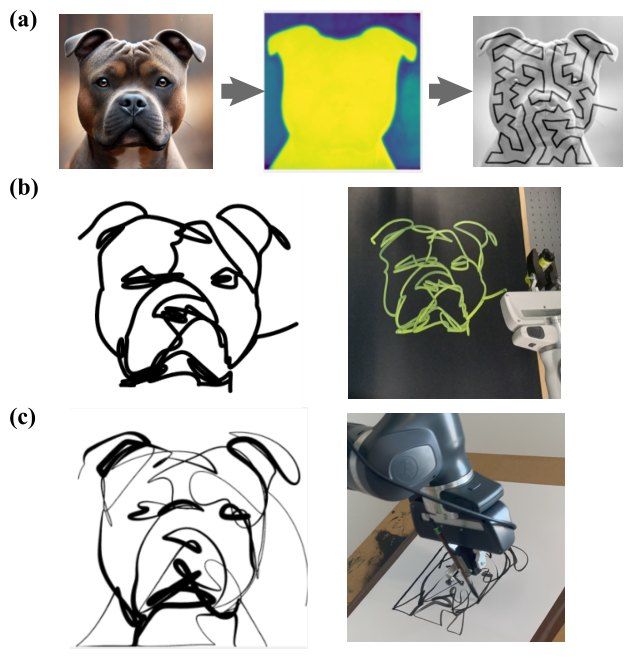
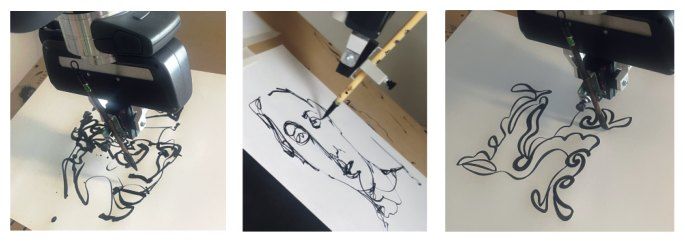
Human drawing and writing are fast, skilled gestures, and the way a hand speeds up and slows down shapes how a line looks. The sigma-lognormal model from the “Kinematic Theory of Rapid Human Movements” describes exactly this. We adapted the model so that it works inside a differentiable vector graphics pipeline: an AI can now optimize natural, human-like drawing motions guided by an image, and the resulting trajectories can be executed by a robot.
Applications include robotic graffiti tags and single-line drawings guided by images or text.
Papers:
Berio, Clivaz, Stroh, Deussen, Plamondon, Calinon. Image-driven Robot Drawing with Rapid Lognormal Movements. IEEE RO-MAN 2025. doi.org/10.1109/RO-MAN63969.2025.11217913
Berio, Calinon, Plamondon, Fol Leymarie. Differentiable rasterization of minimum-time sigma-lognormal trajectories. IGS 2025. PDF
Recent works (2025–2026)
A selection of recent paintings made with e-David using the layered, region-based painting approach developed during EACVA.
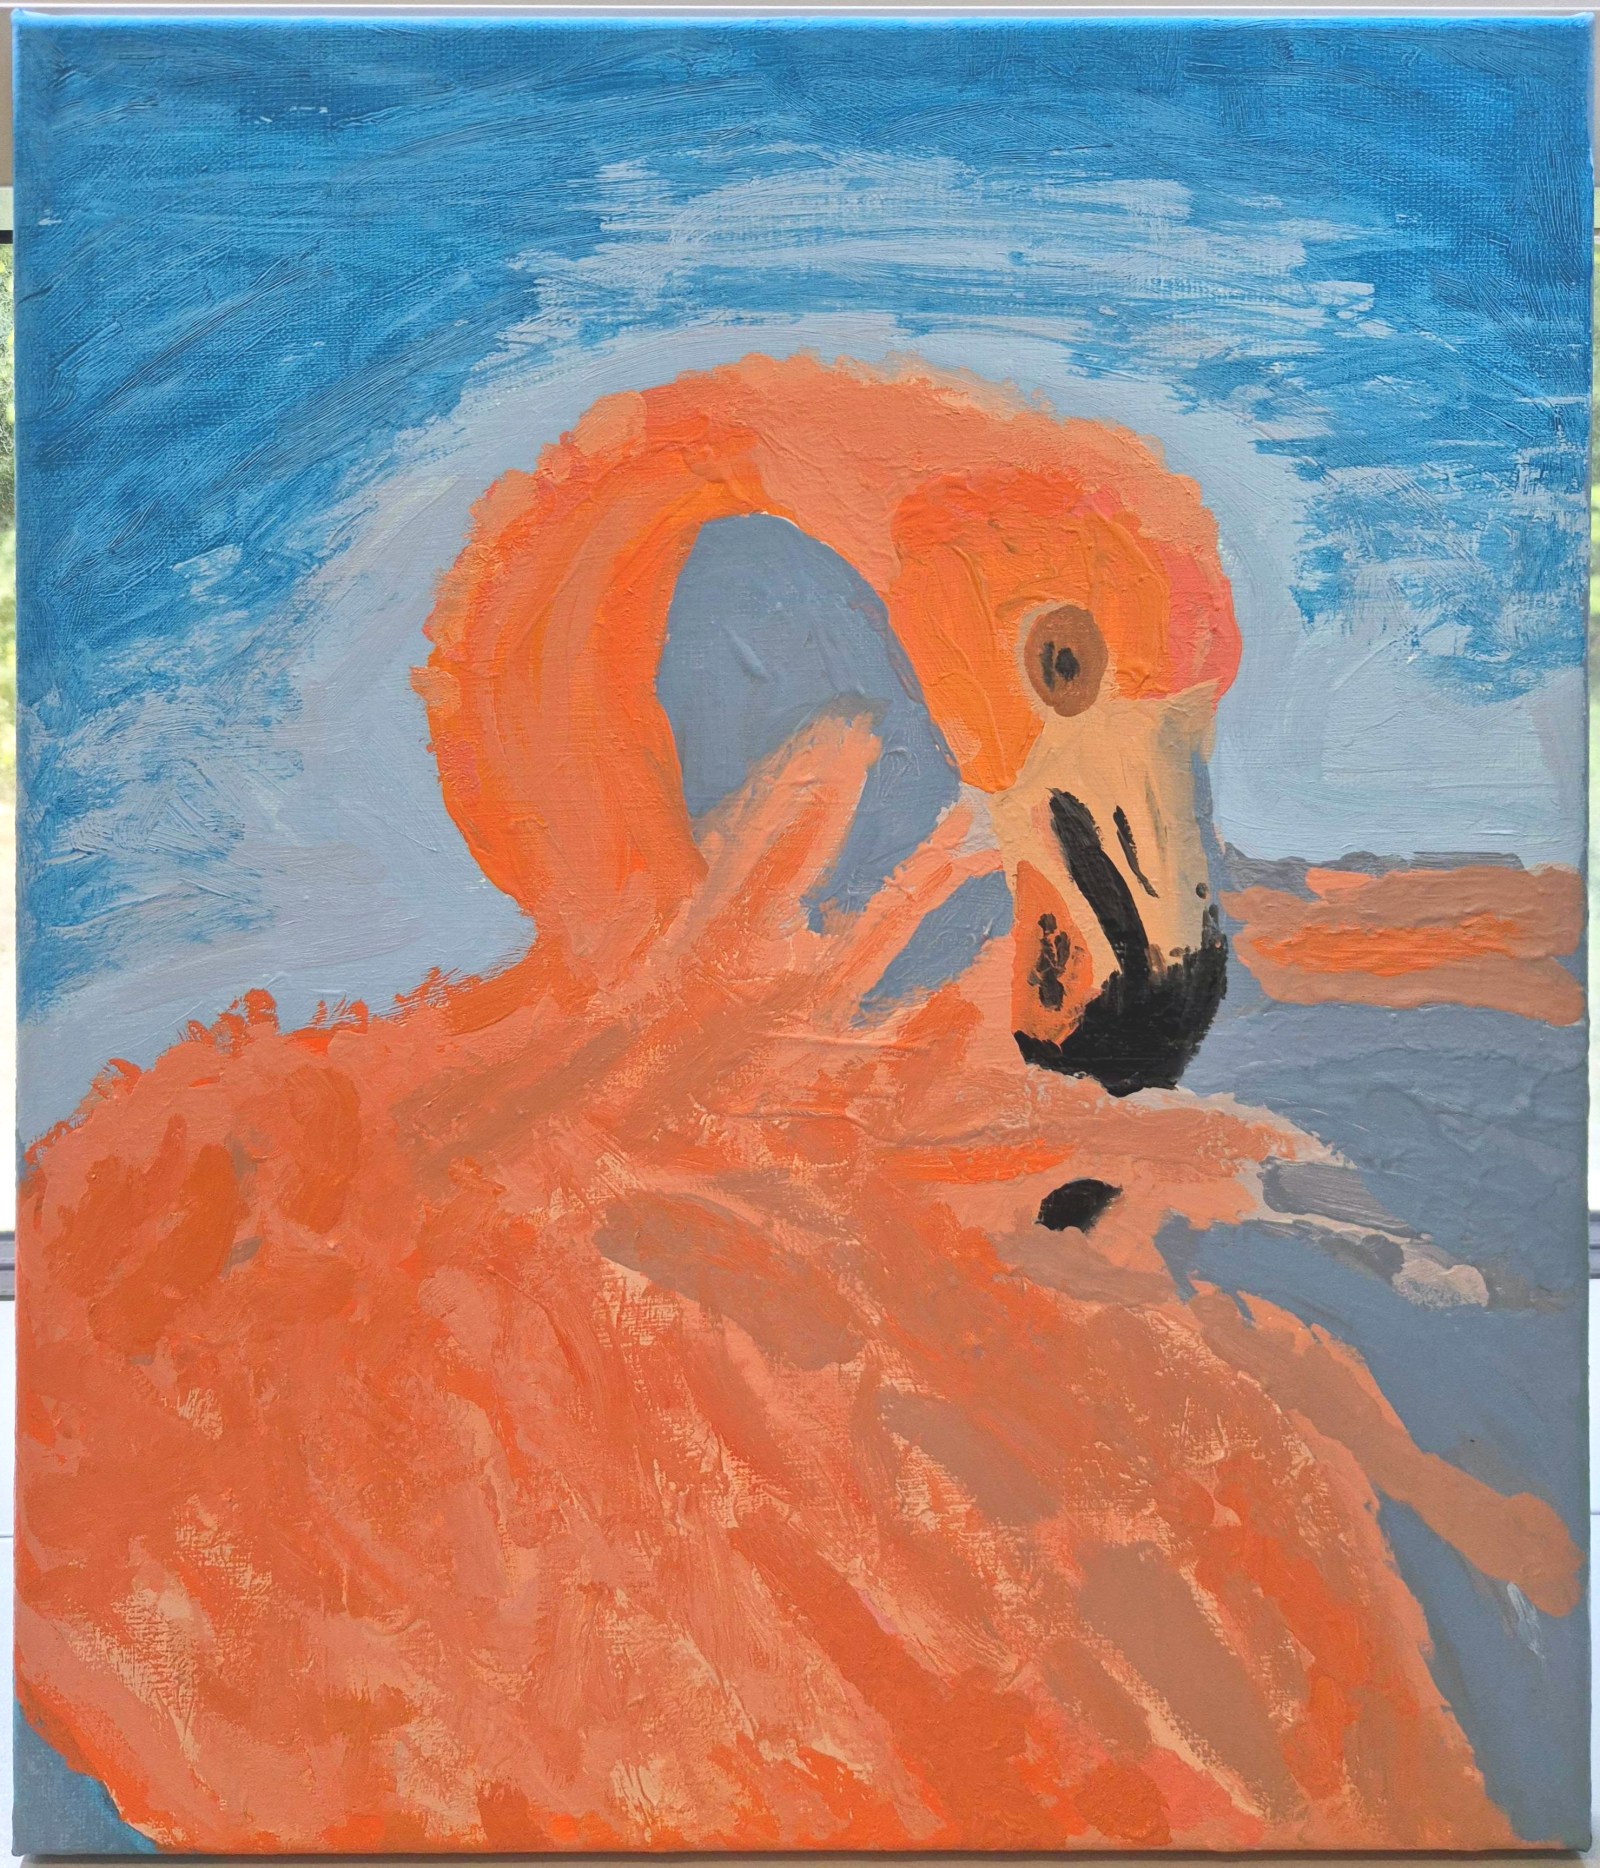
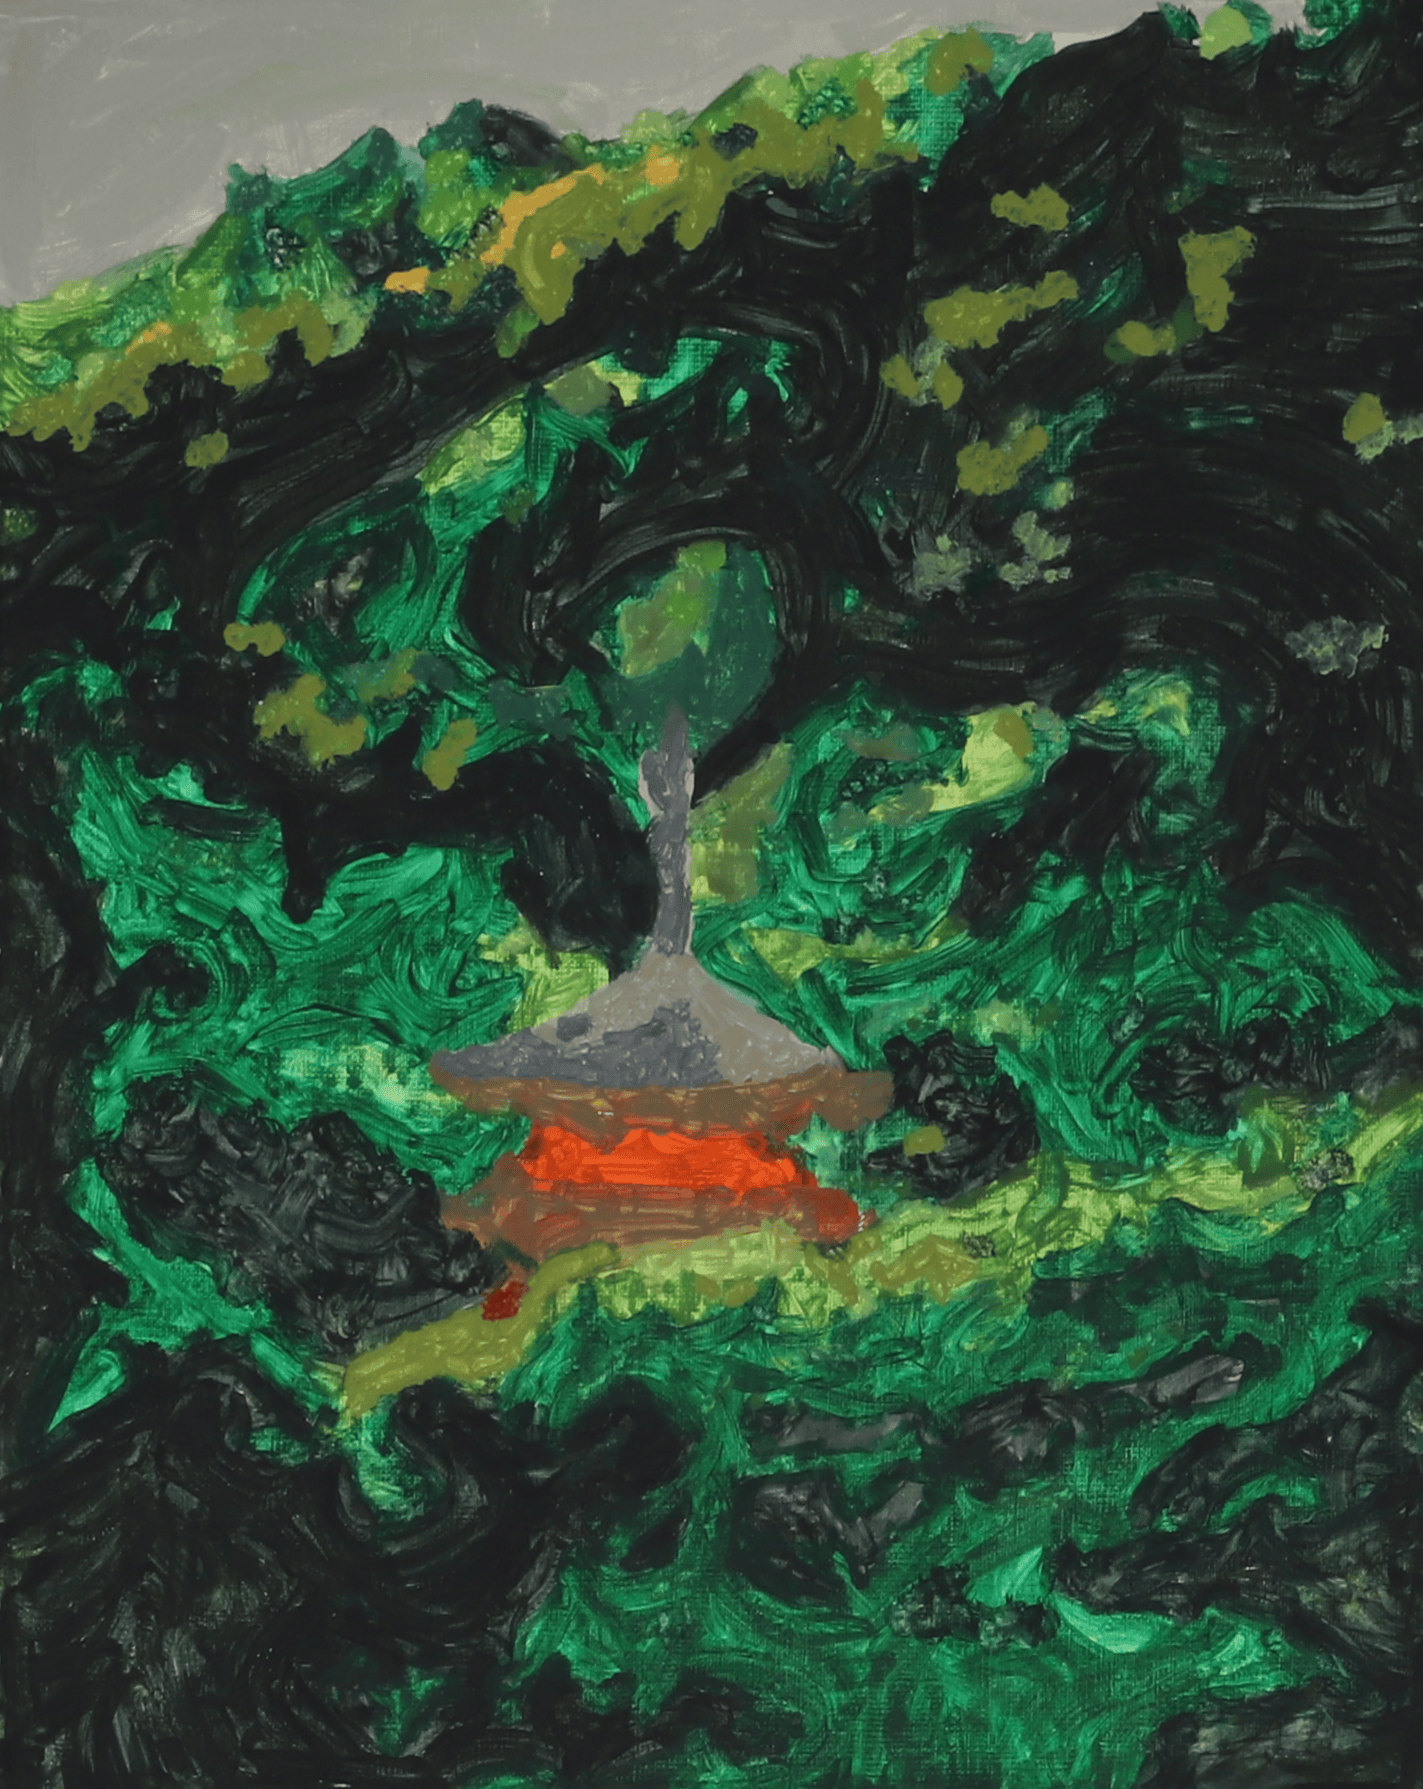
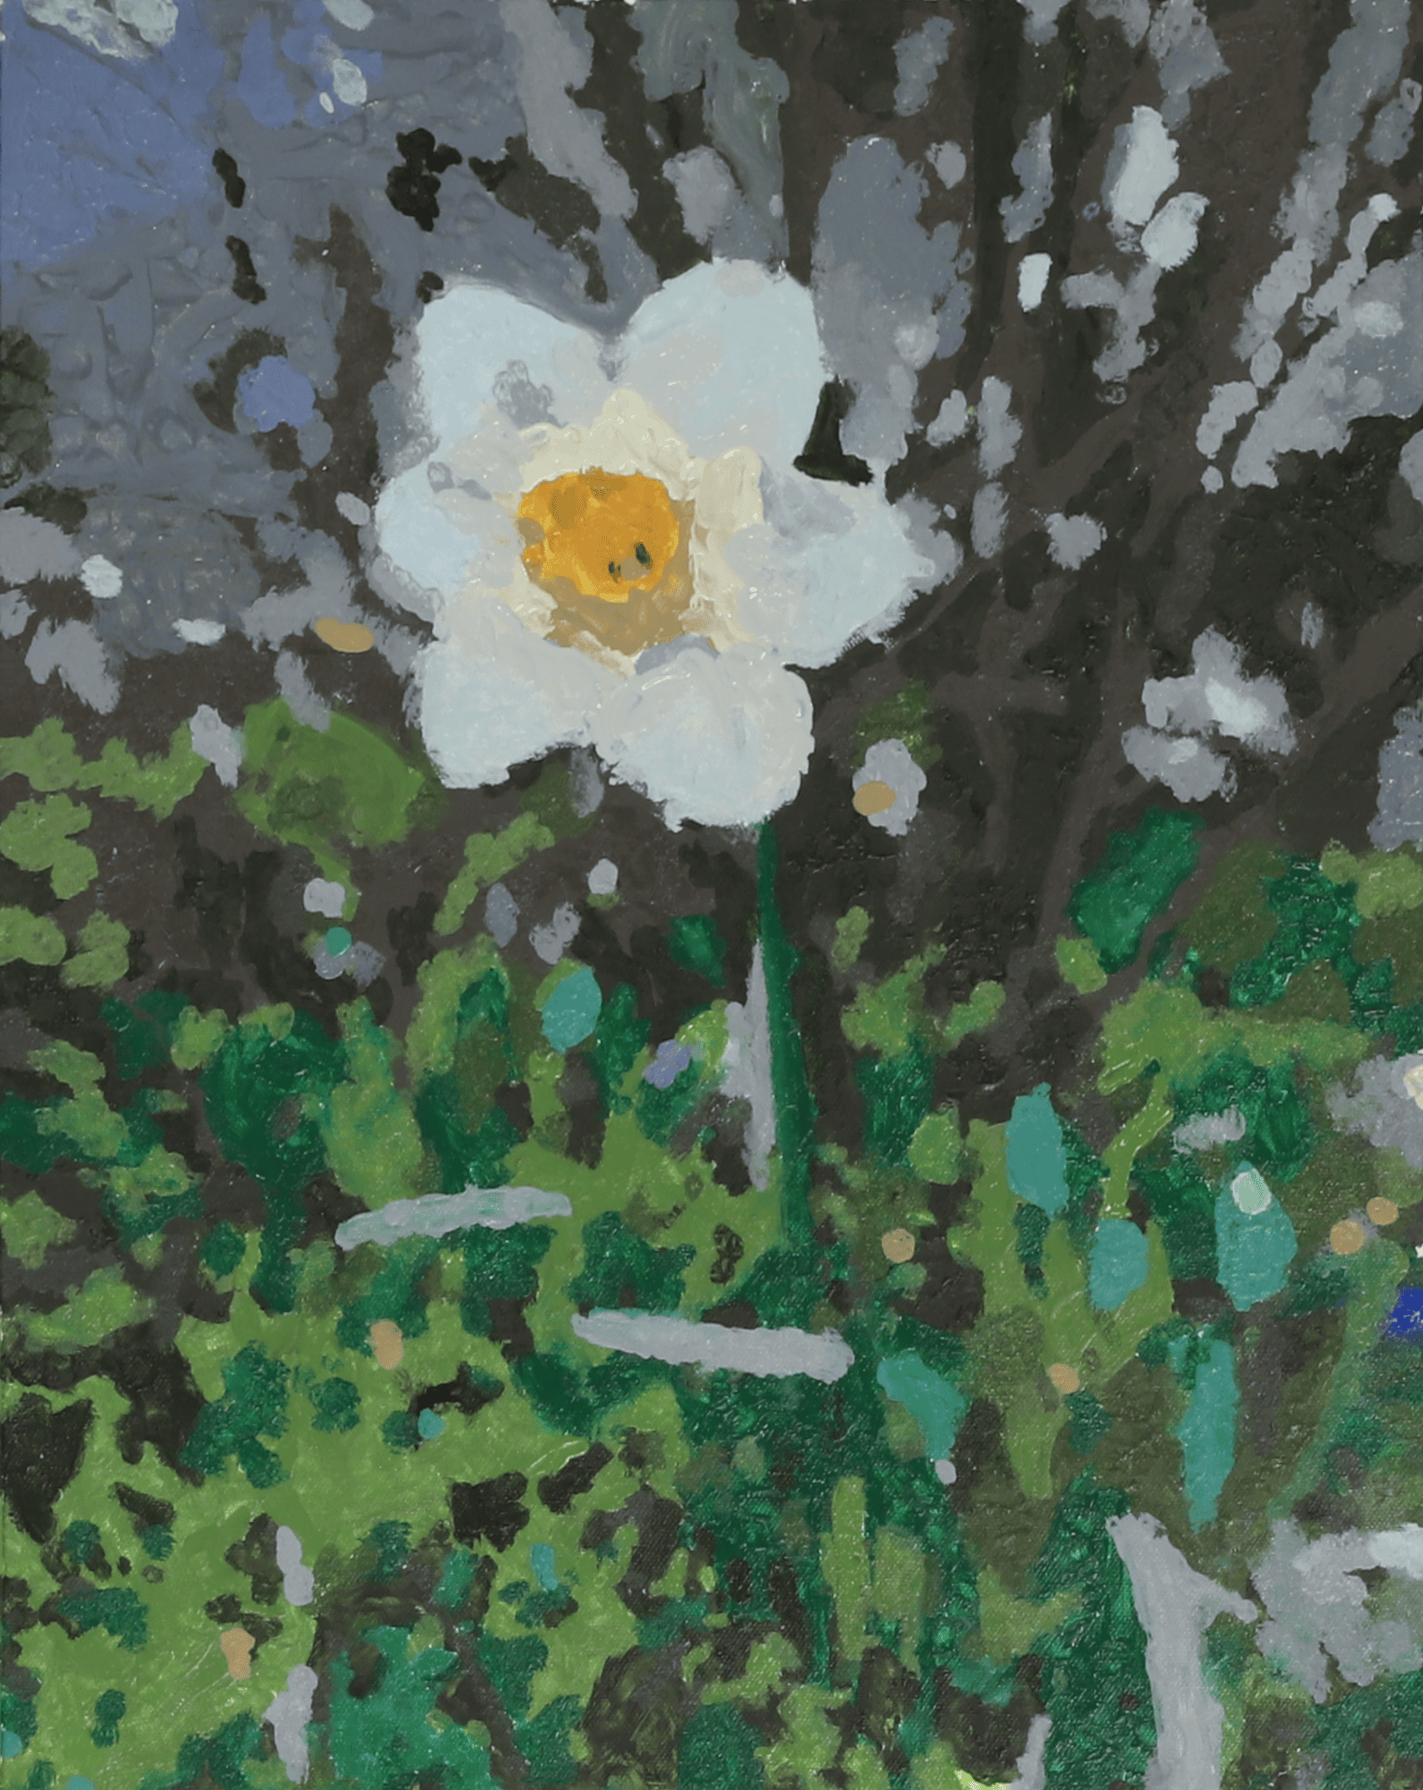
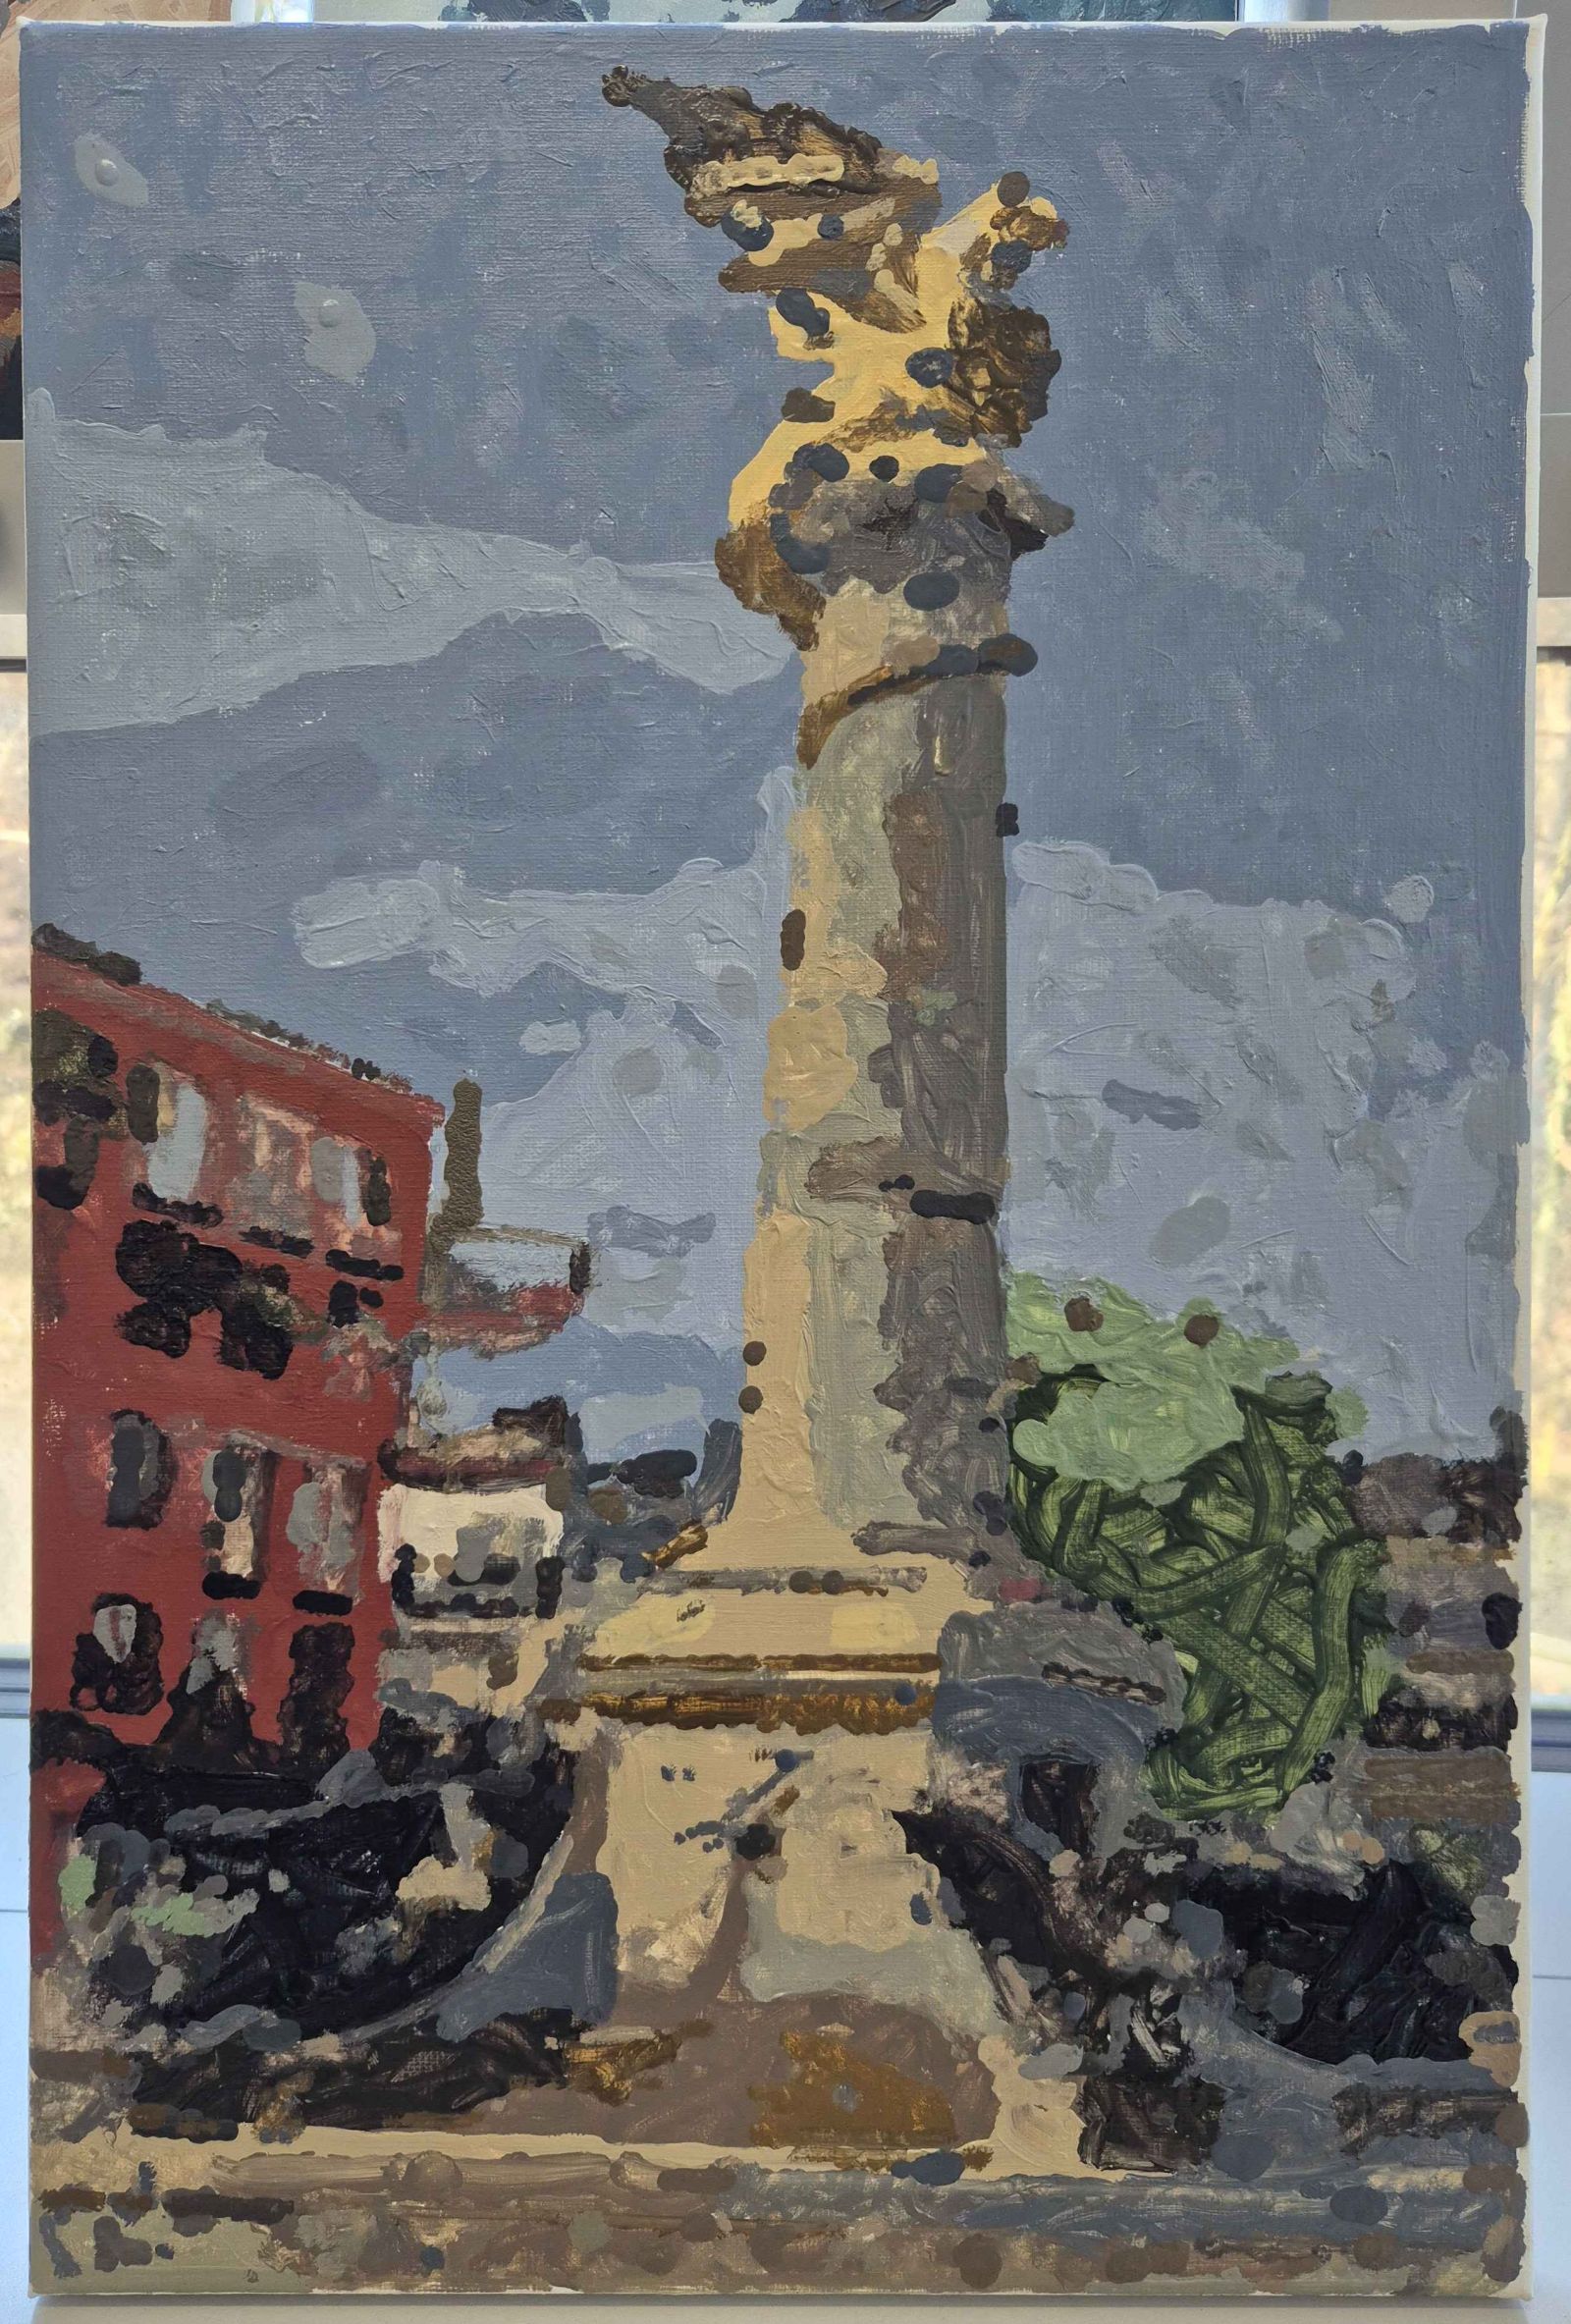
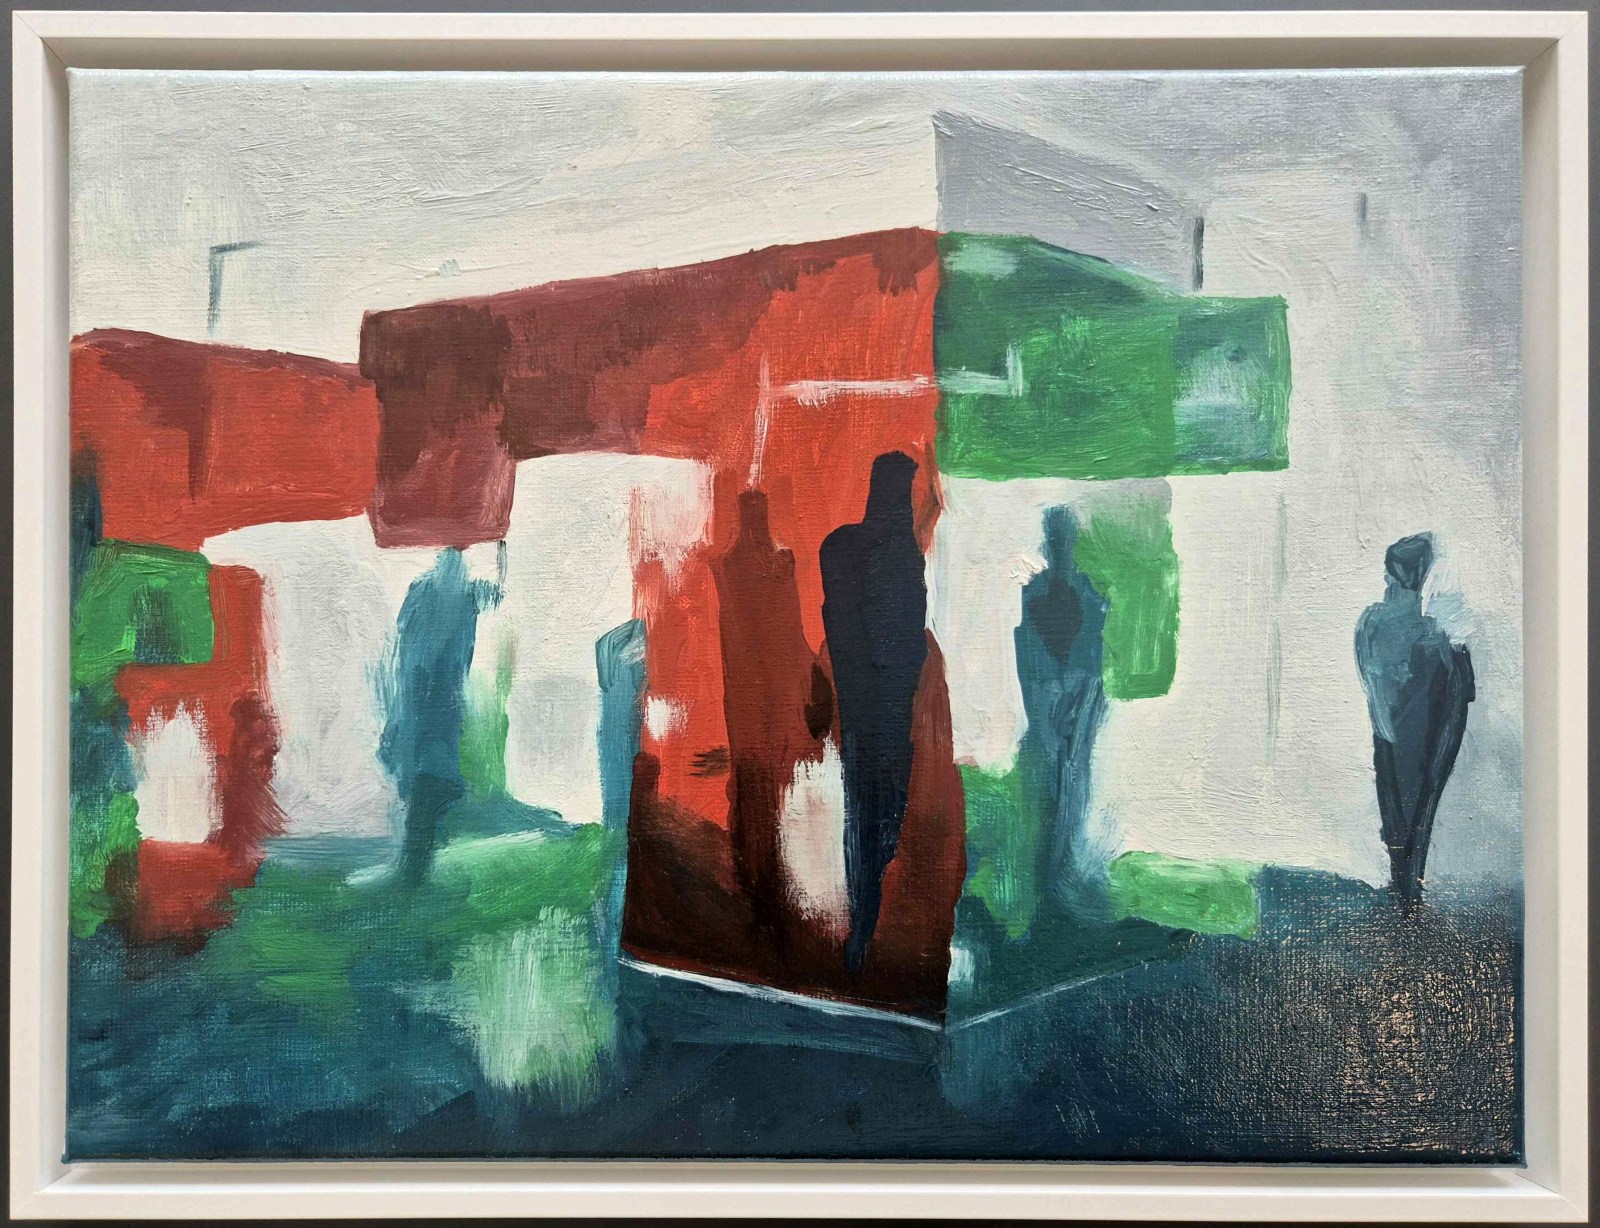
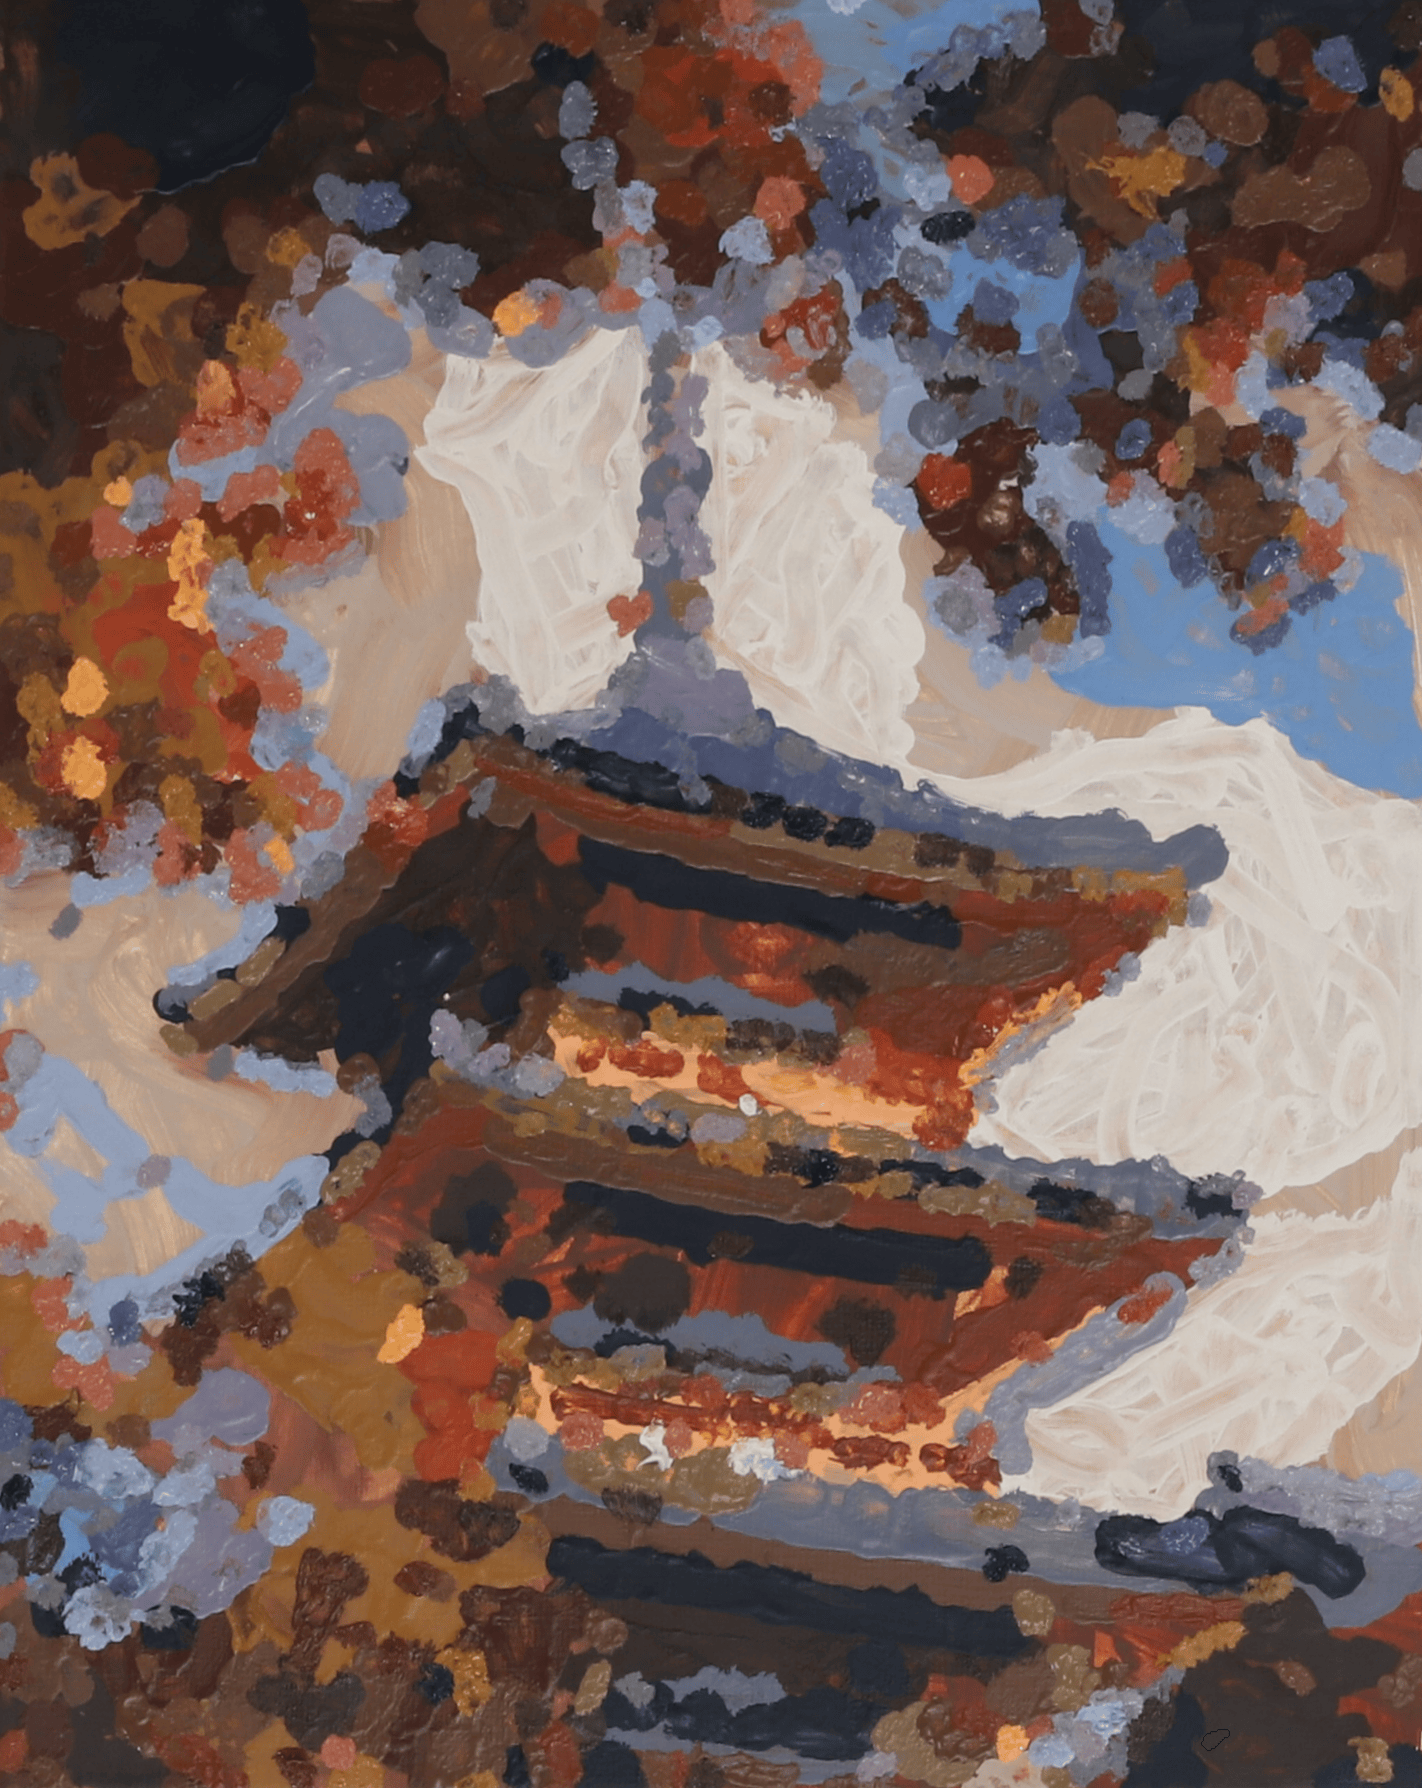
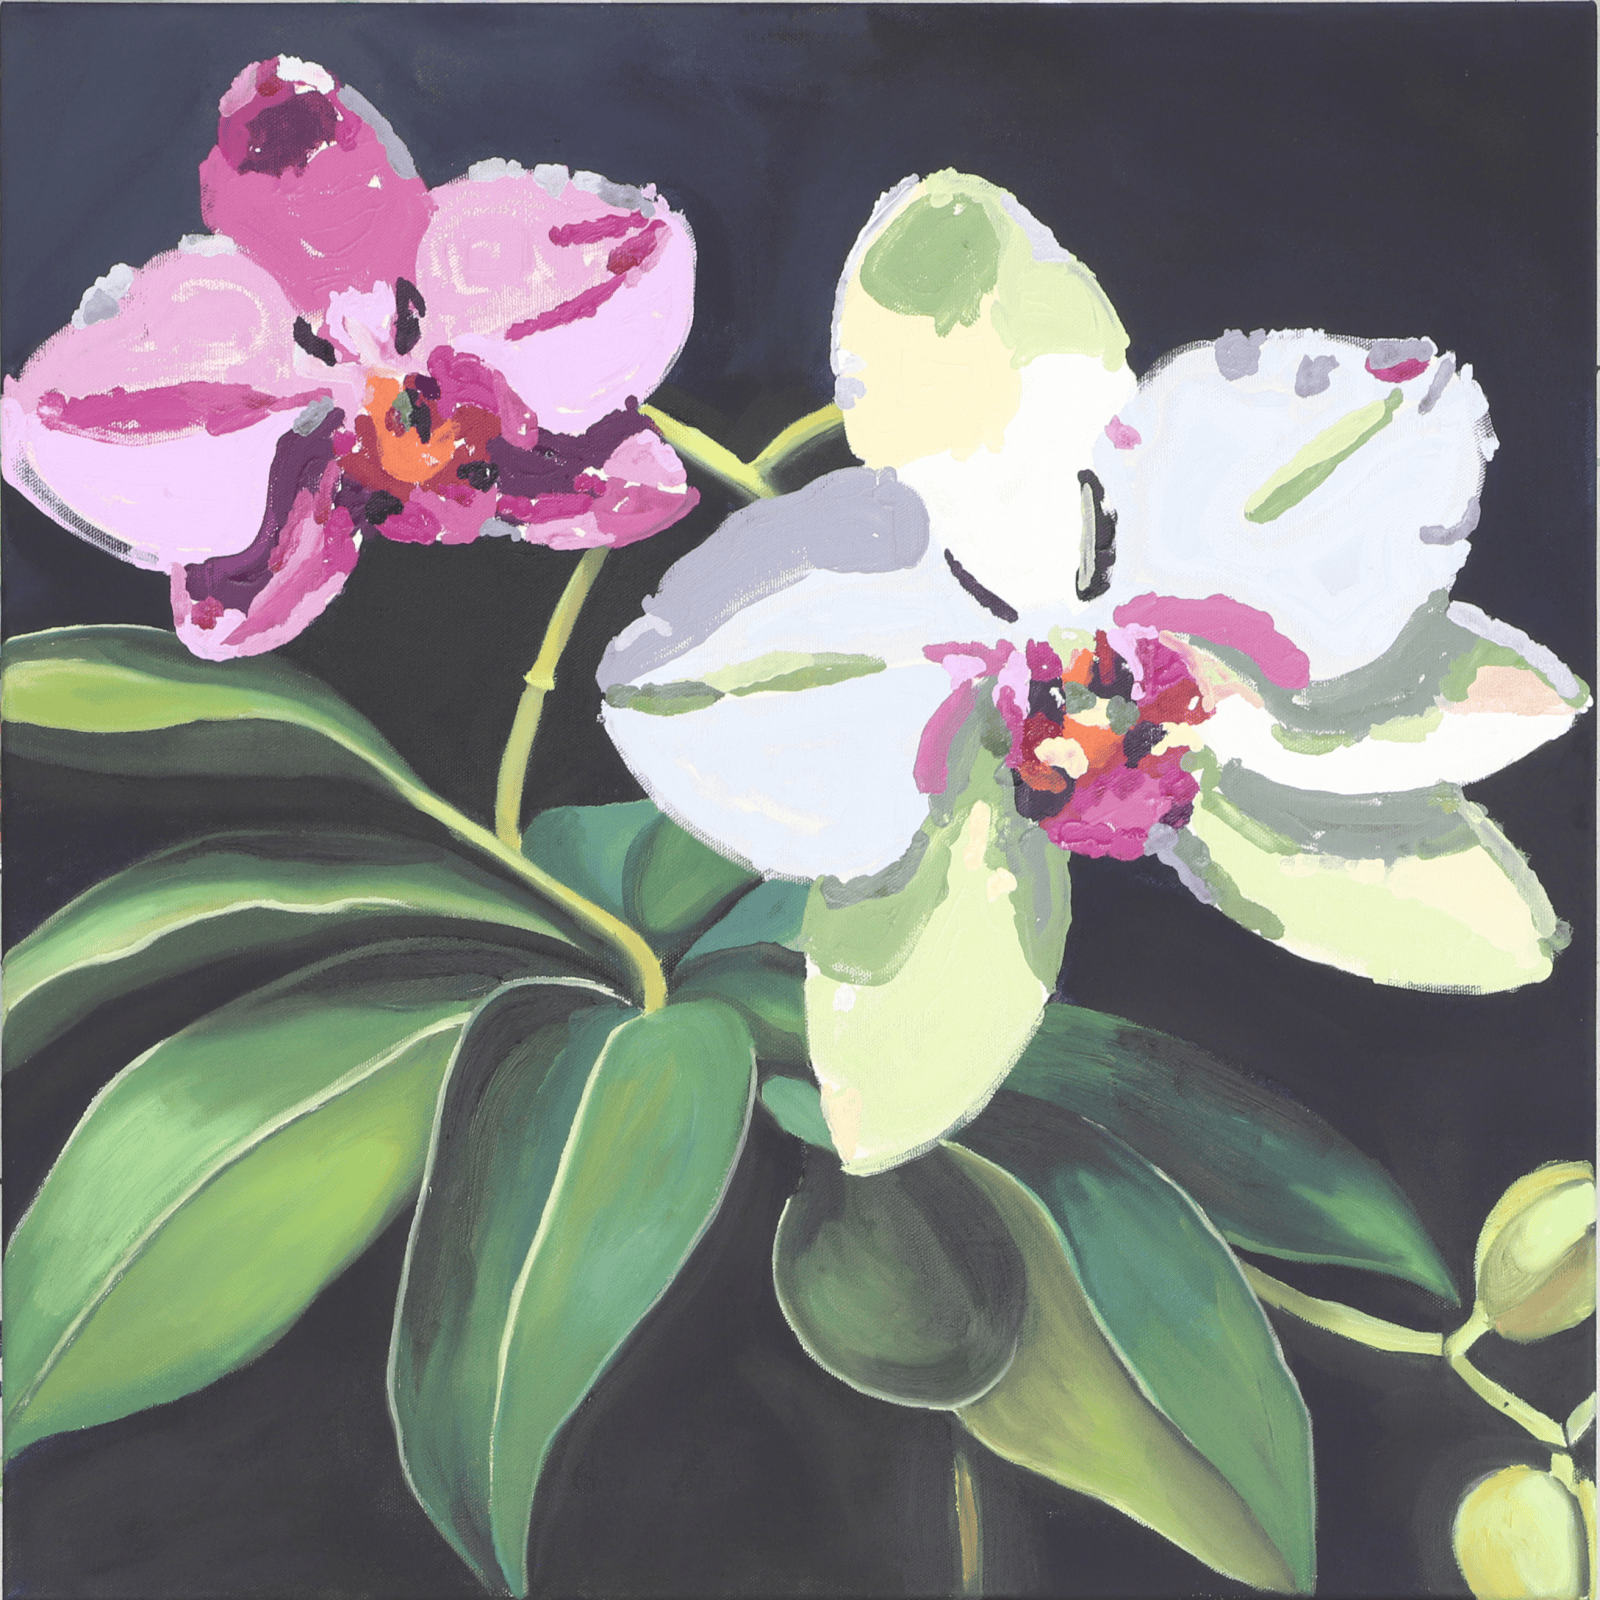
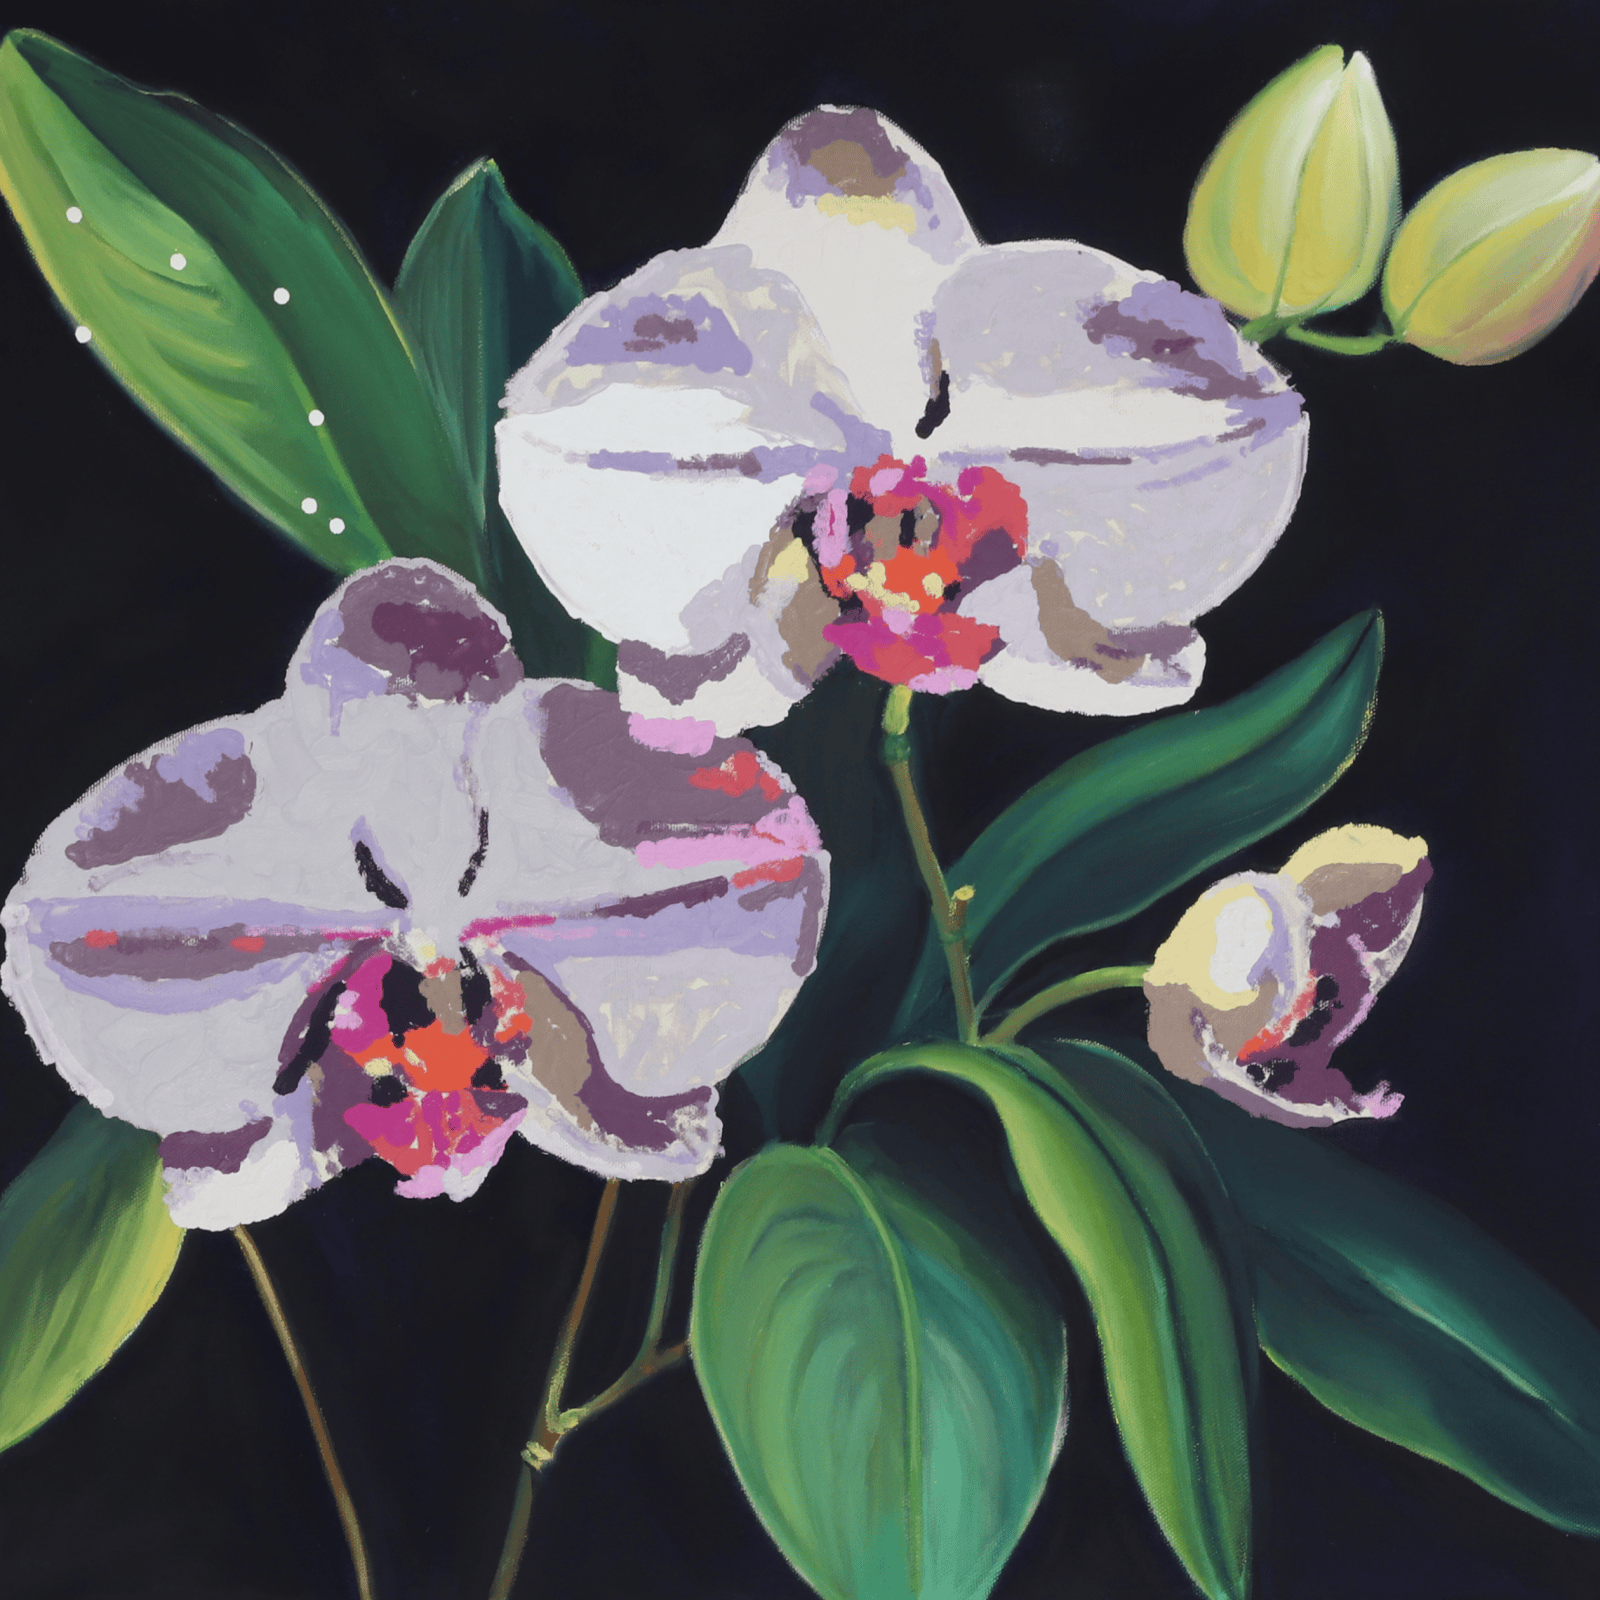
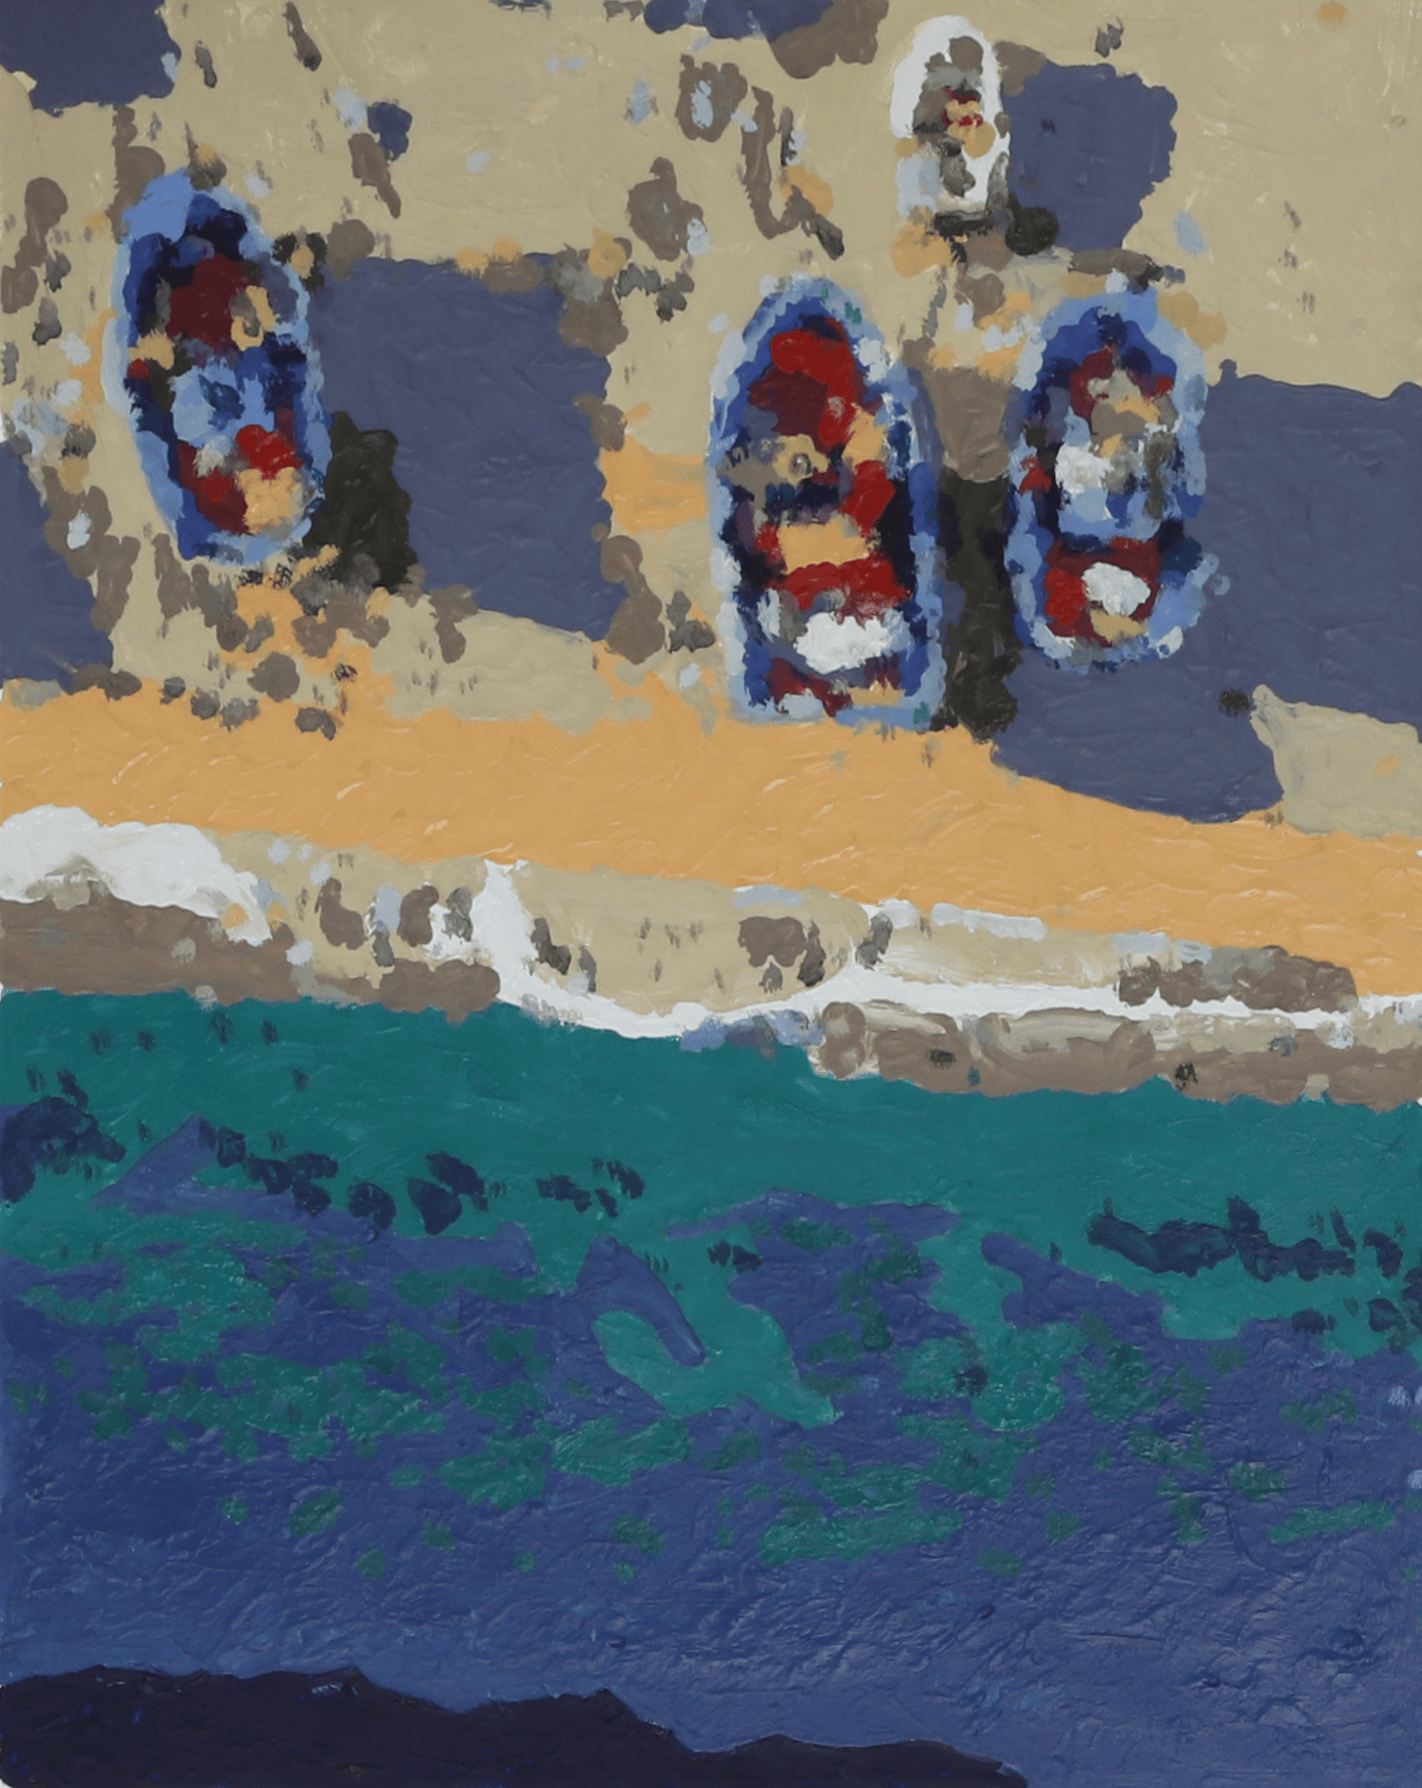
All images: e-David project / Michael Stroh, University of Konstanz. More at edavid.de.
Artists and exhibitions
Collaborations with artists such as Liat Grayver, Anna Mirkin, Patrick Tresset, Gretta Louw and Daniel Berio have shaped e-David from a technical research project into an artistic platform. As part of her EACVA residency, Gretta Louw created the series Artificial Organisms and Animate Machines, in which artist and robot paint alternately on the same canvases. These works were shown at High Tech High Touch (Yvonne Hohner Contemporary, Karlsruhe, 2025) and Code + Paint (DAM Projects, Berlin, 2026). e-David’s works have also been exhibited in Konstanz, Leipzig, Zurich and at the EACVA symposia in Berlin and London, and the project has received several prizes at the international RoboArt competition. The robot regularly paints live at public events, such as the AI+X event in Zurich and the 60th-anniversary open day of the University of Konstanz.
Team
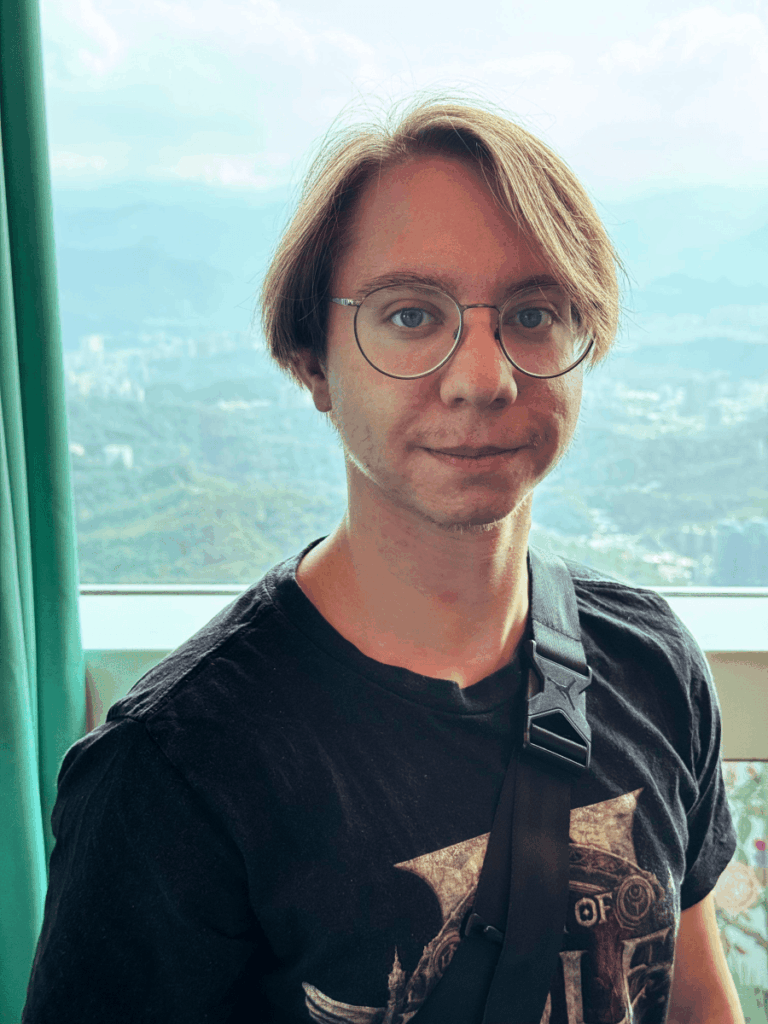
Project Lead – Michael Stroh
Michael Stroh (1999, Friedrichshafen, Germany) is a Ph.D. candidate at the Chair of Visual Computing at the University of Konstanz, where he has worked since 2021, and today leads the e-David project as project lead, manager and artist. After completing his master’s in computer and information science in 2023, his research has focused on interactive robotic painting with AI support: semantic and saliency-driven image abstraction, layered region-based painting, and the realization of digital abstractions as physical paintings.
His current work breaks images down into structured fields of color and form that the robot builds up in successive layers, shifting between precise rendering and expressive abstraction. Within EACVA, he collaborated closely with the artists in residence, in particular Gretta Louw, and with Daniel Berio and Frederic Fol Leymarie at Goldsmiths.
Student projects
Robotic Writing – David Silvan Zingrebe
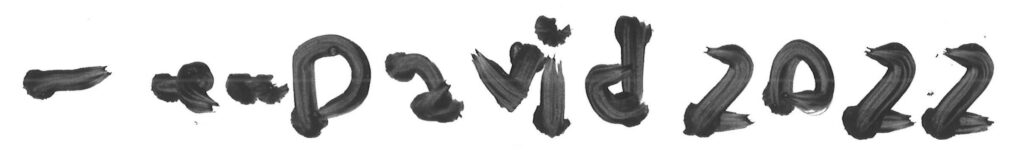
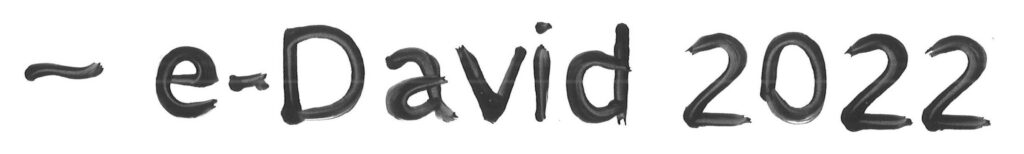
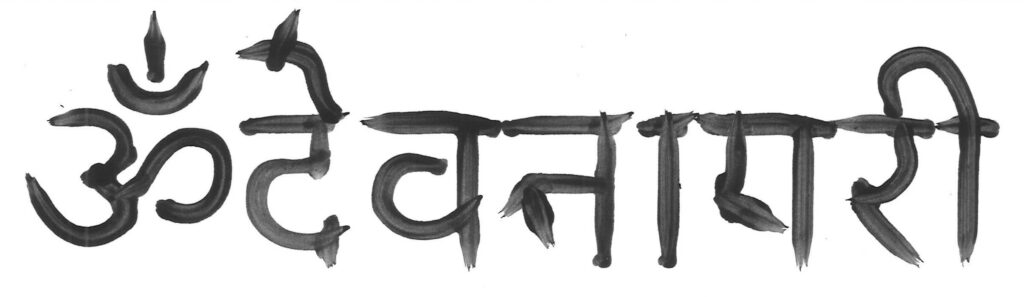
David Silvan Zingrebe developed a modular pipeline that models human handwriting and calligraphy: it computes the centerlines of a text, extracts strokes from them and applies a brush model to account for how the brush behaves. The brush model is obtained by painting calibration strokes and analyzing a photo of the result, which makes it possible to write text in any script – including Devanagari – with a paintbrush.
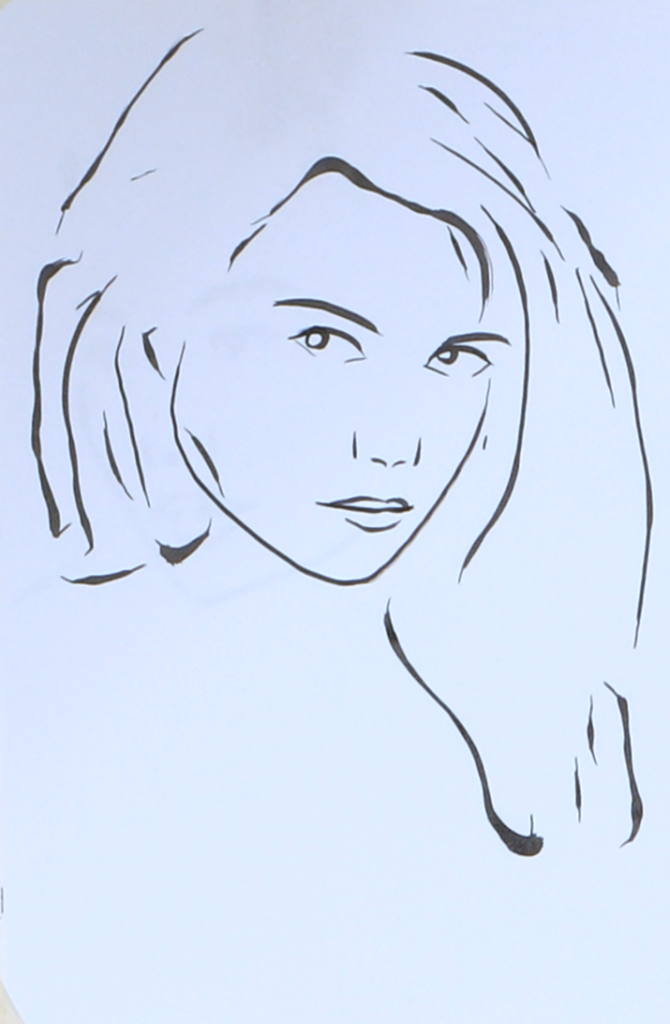
High-Speed Portraiture – Emily Bihler
Emily Bihler’s project emulates how artists construct portraits following the principles of the Loomis method – such as correctly placing the eyes and mouth in relation to each other – and lets e-David draw the result, creating a complete pipeline from image to physical drawing.
Inside the lab
Technical details for artists and researchers who would like to work with e-David.
The painting machines
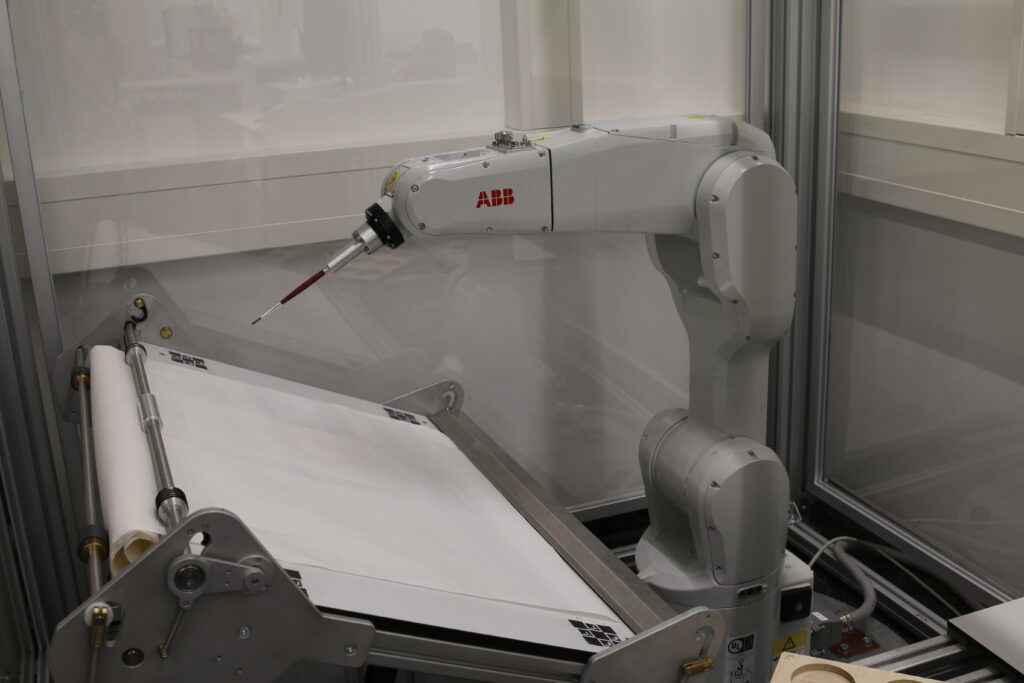
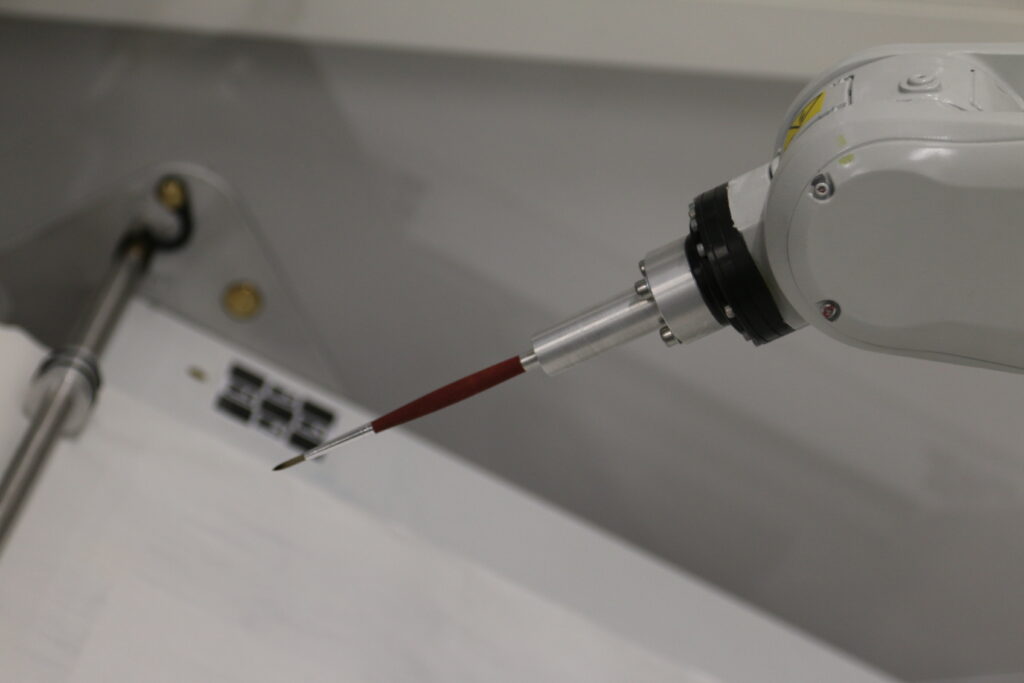
ABB IRB 1660ID – a six-axis industrial welding robot permanently installed in a dedicated room at the university, with a large painting area of about 1 × 1.2 m. A light barrier keeps people safe while it runs in automatic mode.
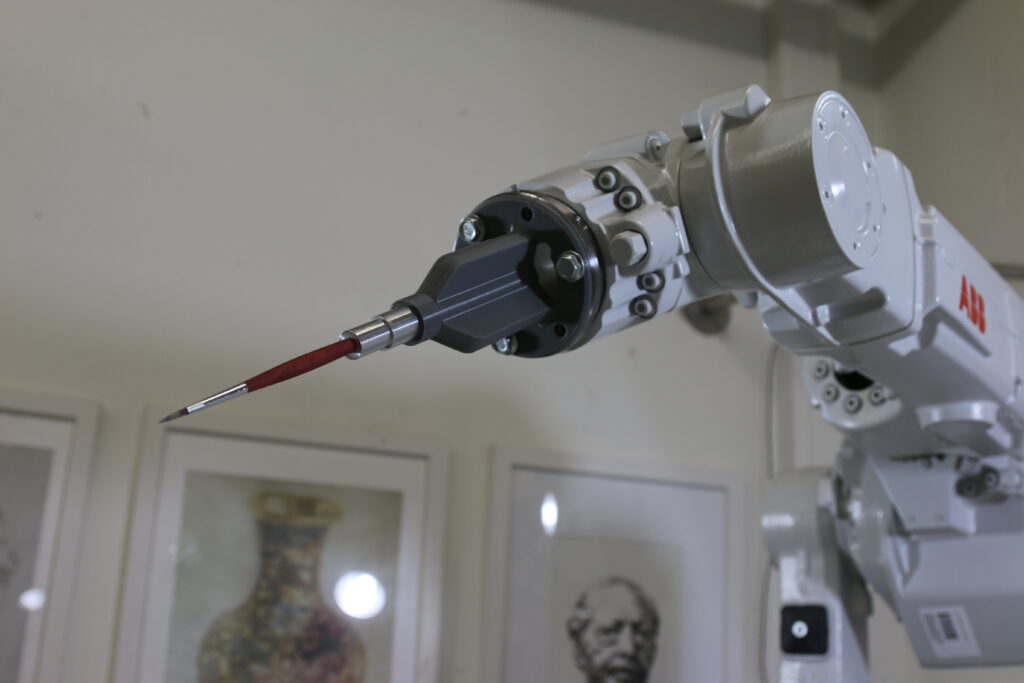
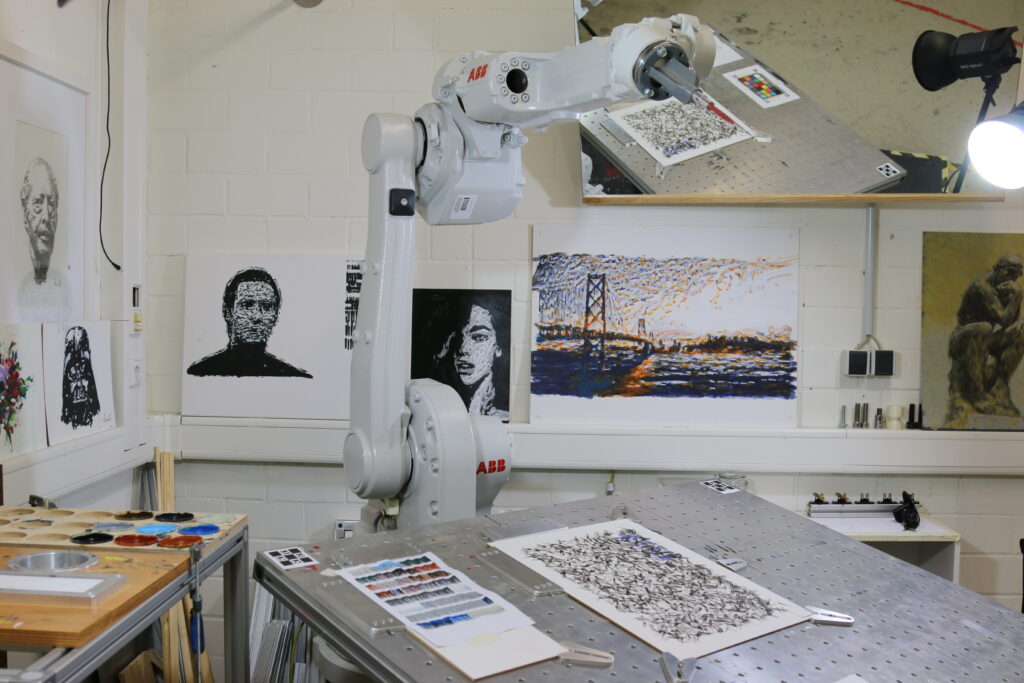
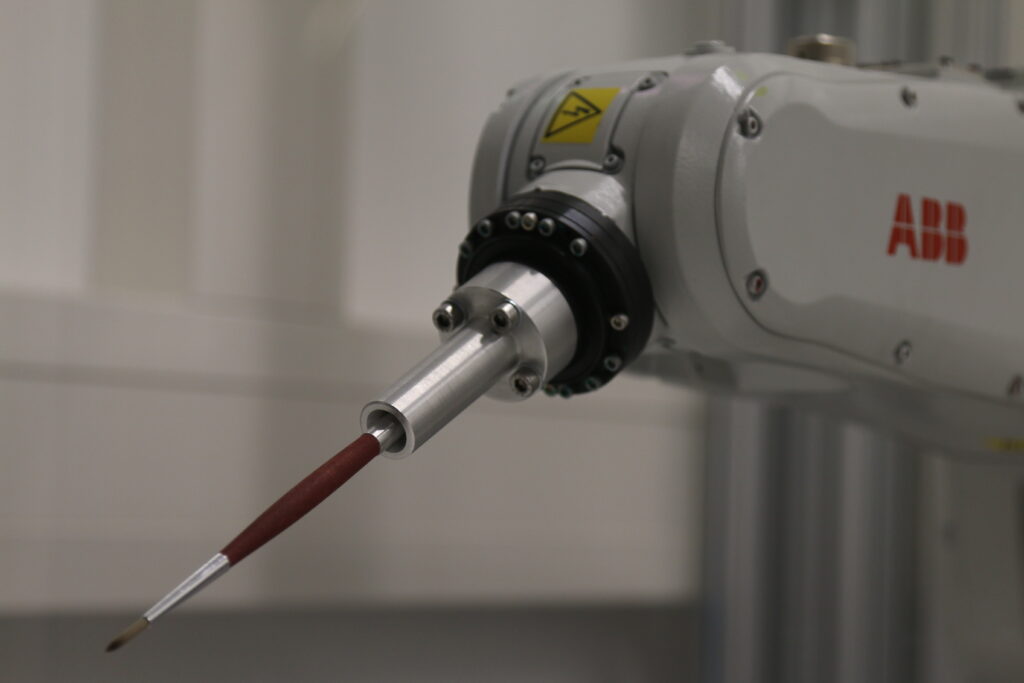
Left: robot arm with the mounted brush holder. Right: the main robot setup (ABB IRB 1660ID). Photos: Michael Stroh, 2023.
ABB IRB 1200 (mobile) – a smaller six-axis robot that runs the same software and can be brought to exhibitions: the setup weighs about 400 kg but splits into parts of at most 50 kg and can be moved by 2–3 people in one day. Its 80 × 60 cm painting surface has an automatic paper feed for “infinite” paintings, and it is enclosed by transparent acrylic walls with a safety door.
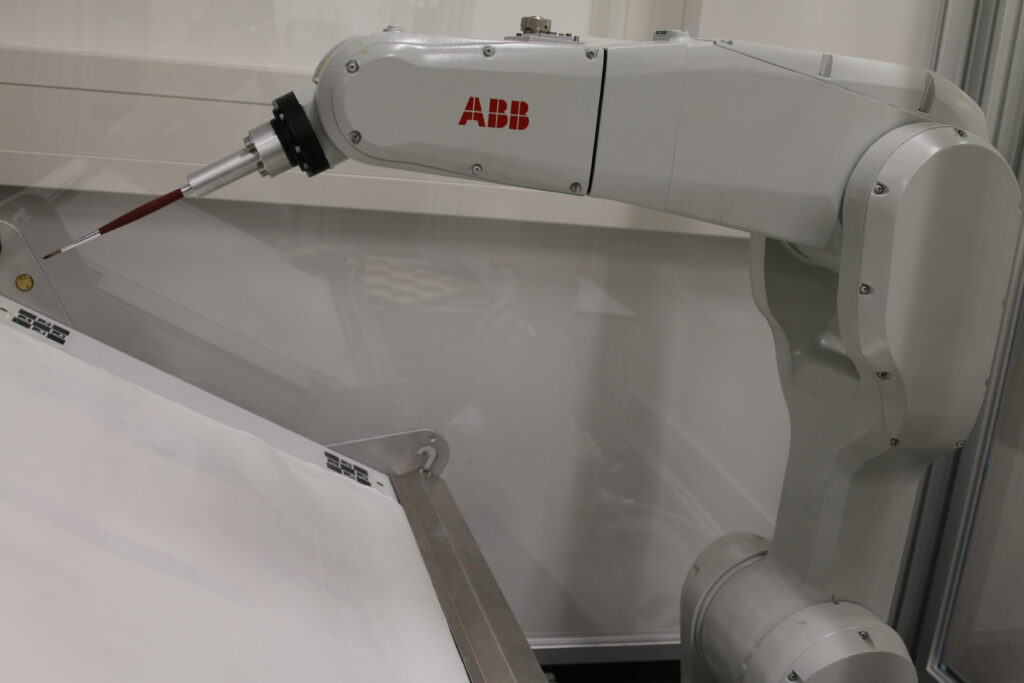
The mobile painting robot (ABB IRB 1200) from different viewpoints. Photos: Michael Stroh and Patrick Paetzold, 2023.
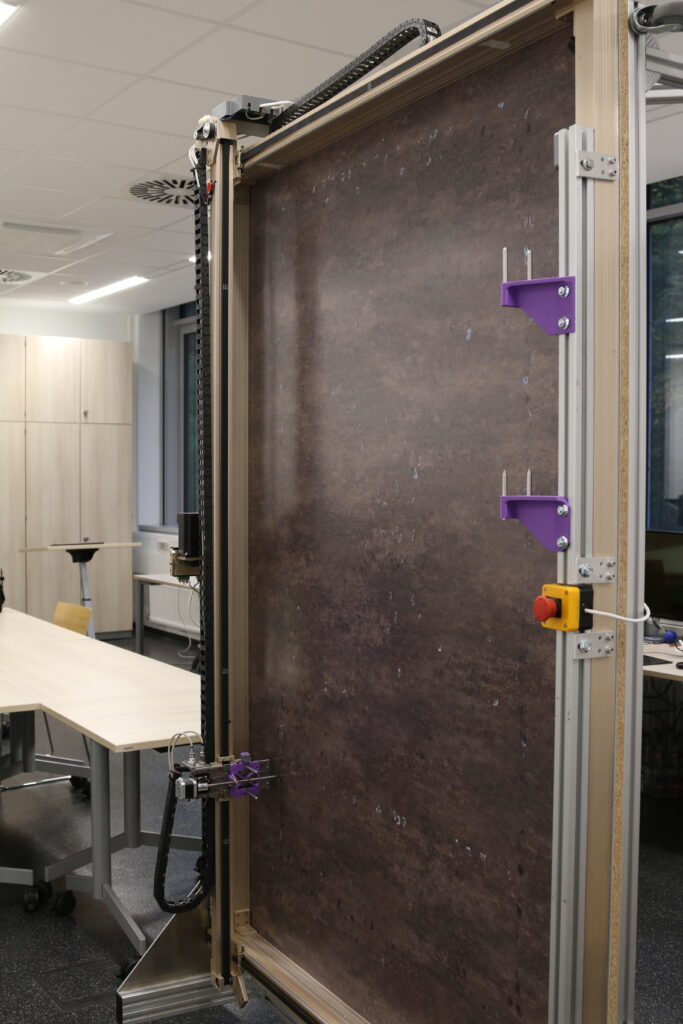
XY plotter – a 2 × 1.2 m pen plotter that can be used lying or standing, controlled via grbl or the e-David software. Pens are attached with 3D-printed adapters.
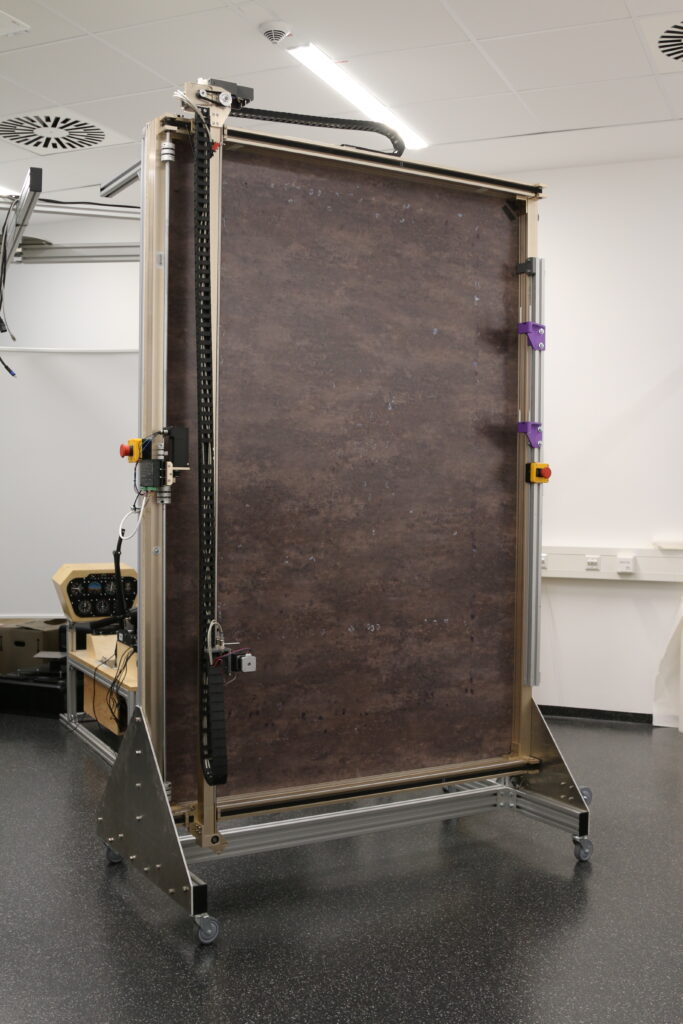
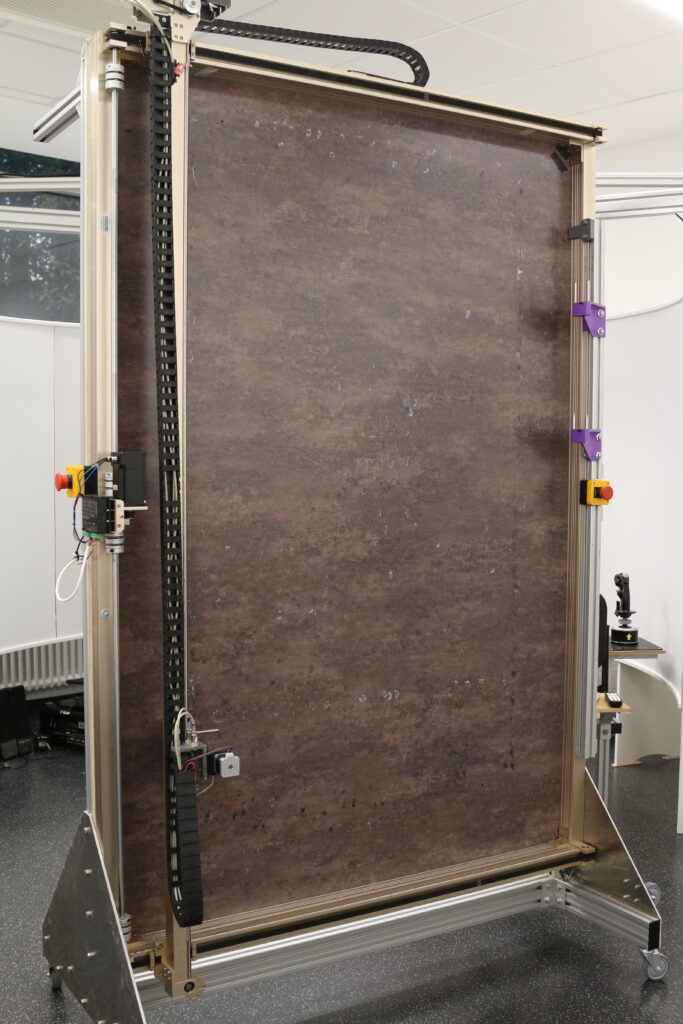
Brushes, palettes and cleaning
Round brushes are held rigidly in a magnet-based holder with zero play, so that only the bristles themselves introduce variation. We currently use nylon round brushes of sizes 2–12; sizes above about 24 do not fit the holders.
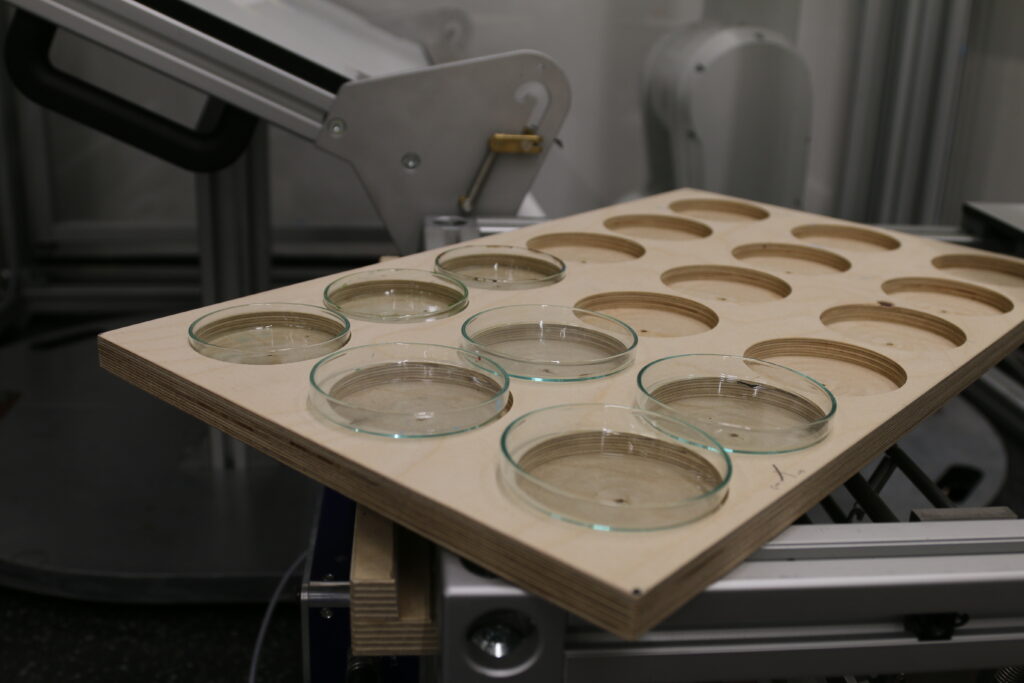
Paint sits in interchangeable wooden palettes holding glass containers – for example nine large beakers for inks, 18 large Petri dishes for general colors or 80 small dishes. New palette layouts can be added in about 30 minutes. To clean a brush, the robot moves it through a water container with a 3D-printed grid just below the surface.
Canvas, camera and markers
The canvas is mounted on a flat surface in front of the robot, whose position is calibrated by touching three corner points. A ceiling-mounted DSLR camera (Canon 6D or 5D) photographs the canvas at about 2.5–3 pixels per millimeter after each batch of strokes, while the robot moves out of view. ChArUco markers in the corners keep the photos aligned, and a color target allows color calibration.
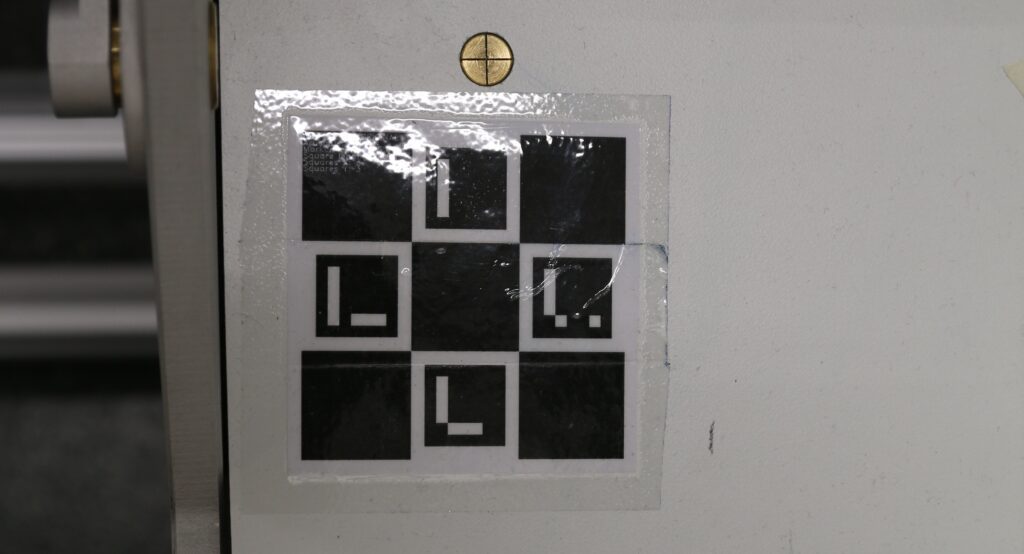
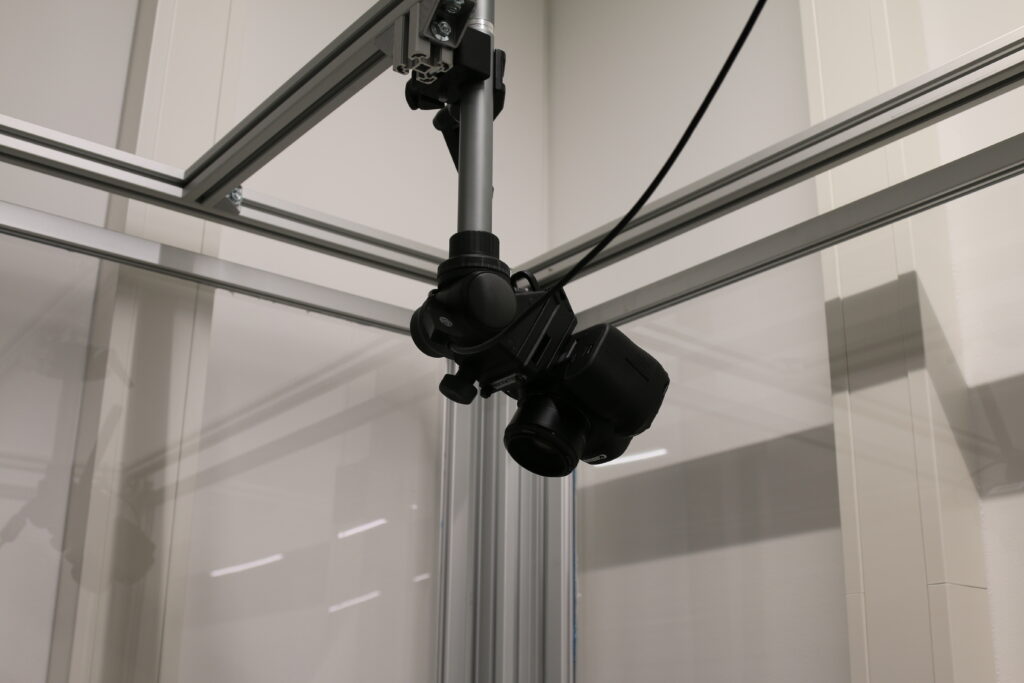
Left: ChArUco marker used to track the canvas. Right: feedback camera of the mobile robot. Photos: Michael Stroh, 2023.
Software
- Robot controller – each arm runs an ABB IRC5 controller programmed in RAPID, which receives stroke points, color pick-up and brush-cleaning commands over the network.
- e-David driver – coordinates commands, robot state and camera feedback. Users write simple command files; feedback images are stored automatically.
- ShapePainter – the highest level: takes SVG images with paintable regions and fills each region with one or more “painting agents” written in Python, e.g. agents that follow a shape’s outline or apply a stroke pattern. Calibrations such as a pressure-to-stroke-width function reach an accuracy of ±0.1 mm.
Materials and limitations
e-David works with most materials; we mostly use acrylic paint (Schmincke, Liquitex), round nylon brushes (da Vinci) and white cardboard or paper. Gouache and water-mixable oil paints have also been used successfully; conventional oil paints are discouraged because of their long drying time and difficult cleaning.
- Painting speed is currently limited to 100 mm/s.
- Taking a feedback photo takes a few seconds, during which the robot cannot paint.
- Holding the brush at steep angles requires care to avoid robot singularities.
- For safety, nobody may approach the robots while they paint in automatic mode.
History
2024–2026: Semantic abstraction and human-like movement (EACVA)
Saliency-guided, layered abstraction; long smooth strokes and human-like drawing motions; collaborations with artists in residence and exhibitions in Karlsruhe, Berlin and London – see the research highlights above.
2022–2024: Region-based abstraction and painting
AI-based panoptic segmentation was added to the region abstraction: each object in an image automatically gets suitable abstraction parameters, producing around 1,000–1,500 regions that the robot can paint in about a day.
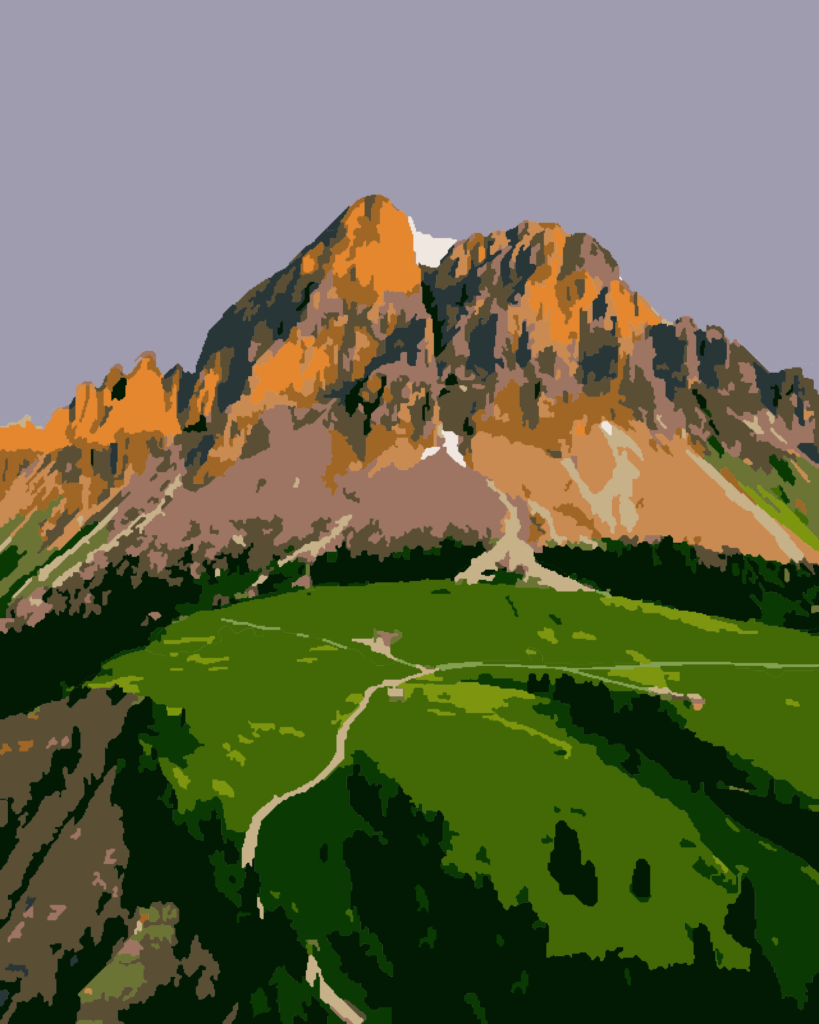
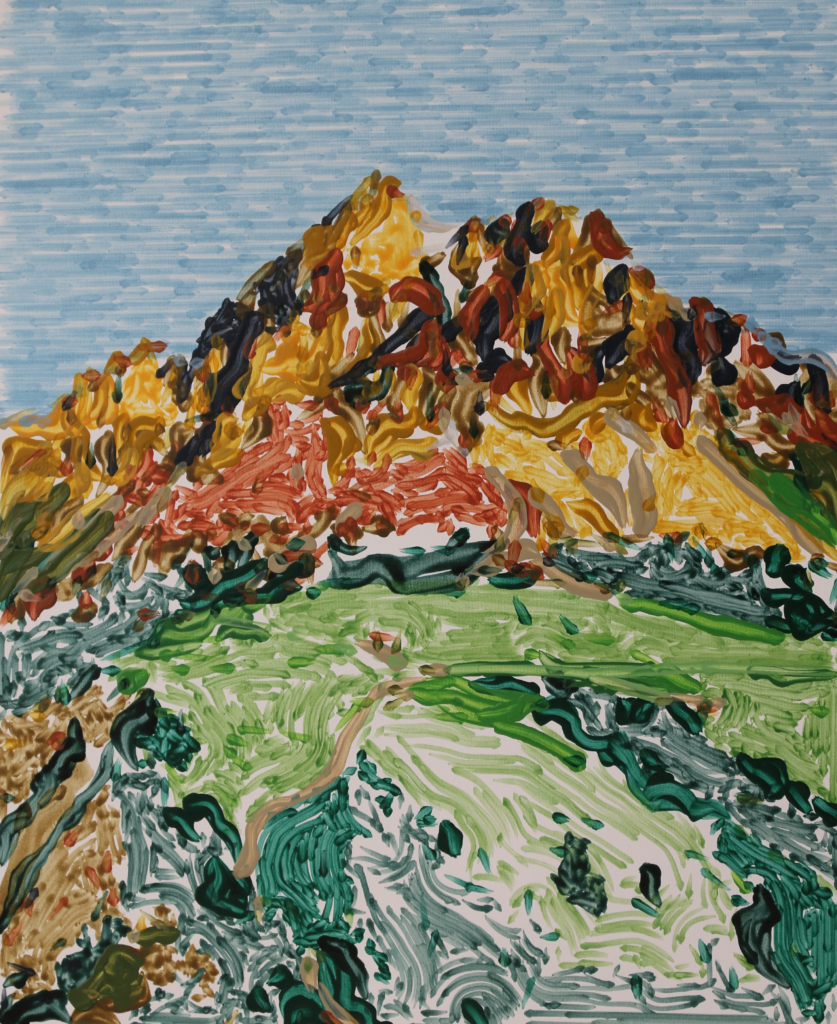
Left: digital abstraction with about 1,000 regions. Right: “Flowing Mountain Meadow”, acrylic on cardboard, 60 × 40 cm, 2023, by Michael Stroh & Jörg-Marvin Gülzow.
2018–2022: Painting with regions
Inspired by painters such as Paul Cézanne, Robert Delaunay and Wassily Kandinsky, the team moved from iteratively placing brushstrokes to painting individual regions with specific characteristics. The software was rebuilt in layers so that users can work on one part – e.g. new brushstroke styles – without knowing the rest, and a new brush calibration made precise line drawing and text possible.
2016–2018: Modernization
The system moved to ABB robots with better programming and more precise moves. Brush holders, palettes and brush washing were redesigned to be cheap and easy to reproduce, including the play-free magnetic tool holder, and the camera system was made more robust.
2013–2016: Painting in color
The software learned to handle grayscale and multicolor palettes and to switch brushes while painting, using quick-drying acrylic paints. Computer vision helped recognize objects in the input image and paint them in different styles.
2012–2013: First paintings with visual feedback
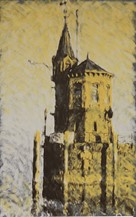
Using black ink on paper, the robot compared the canvas with the original through a camera and added strokes where the canvas was still too light. Stroke length and curvature varied by image area – short strokes for a meadow, long strokes following the structure of a tree.
2009–2012: Building the robot
Besides installing the robot arm, the team built everything else – brush holders, palette and cleaning system – and wrote the first painting software, which still worked without visual feedback. The first images were drawn with felt-tip pens and varying pressure to create shades of gray.
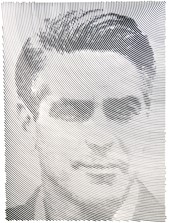
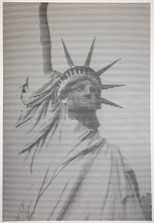
Works from 2009–2017 by Dr. Thomas Lindemeier using e-David.
What’s next
We are moving away from reproducing a fixed template image towards an open, interactive canvas: artists will be able to draw with a tablet or pen display, combine their own strokes with image crops and AI-generated elements, and let the robot paint selected parts whenever they want – so that human and machine can work side by side on the same painting.
Selected publications
- Berio, Stroh, Calinon, Fol Leymarie, Deussen, Shamir: Neural Image Abstraction using Long Smoothing B-Splines. ACM Transactions on Graphics 44(6), 2025. DOI
- Stroh, Paetzold, Berio, Kehlbeck, Fol Leymarie, Deussen, Faraj: Using Saliency for Semantic Image Abstractions in Robotic Painting. Computer Graphics Forum 44(7), 2025. DOI
- Berio, Clivaz, Stroh, Deussen, Plamondon, Calinon: Image-driven Robot Drawing with Rapid Lognormal Movements. IEEE RO-MAN 2025. DOI
- Berio, Calinon, Plamondon, Fol Leymarie: Differentiable rasterization of minimum-time sigma-lognormal trajectories. IGS 2025. PDF
- Stroh, Paetzold, Berio, Fol Leymarie, Kehlbeck, Deussen: Robotic Painting using Semantic Image Abstraction. Expressive 2025. DOI
- Stroh, Gülzow, Deussen: Semantic Image Abstraction using Panoptic Segmentation for Robotic Painting. VMV 2023. DOI
- Zingrebe, Gülzow, Deussen: Robotic Writing of Arbitrary Unicode Characters Using Paintbrushes. Robotics 12(3), 2023.
- Gülzow, Deussen: Region-Based Approaches in Robotic Painting. Arts 11(4), 2022.
All EACVA publications: Publications page.